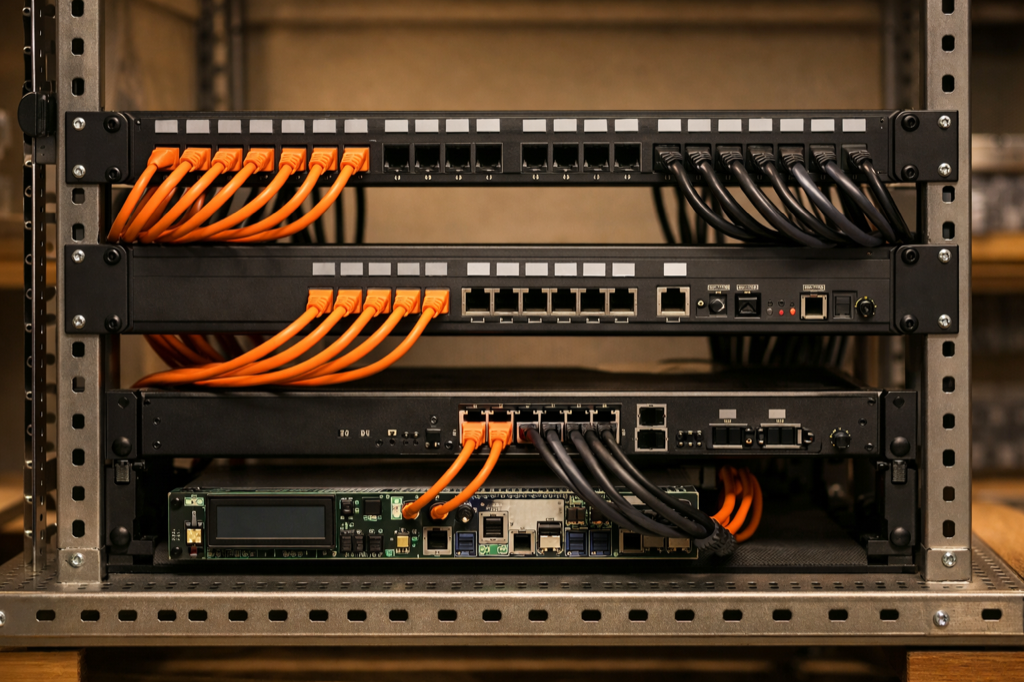
Storage
P0Build Now
Local Dataset NAS
A durable local home for robotics video, CAD, logs, datasets, and checkpoints before any compute expansion.
NASZFSdatasets
Robots, sensing, local AI, and the tools to build them. Find your next lab project.
A durable local home for robotics video, CAD, logs, datasets, and checkpoints before any compute expansion.
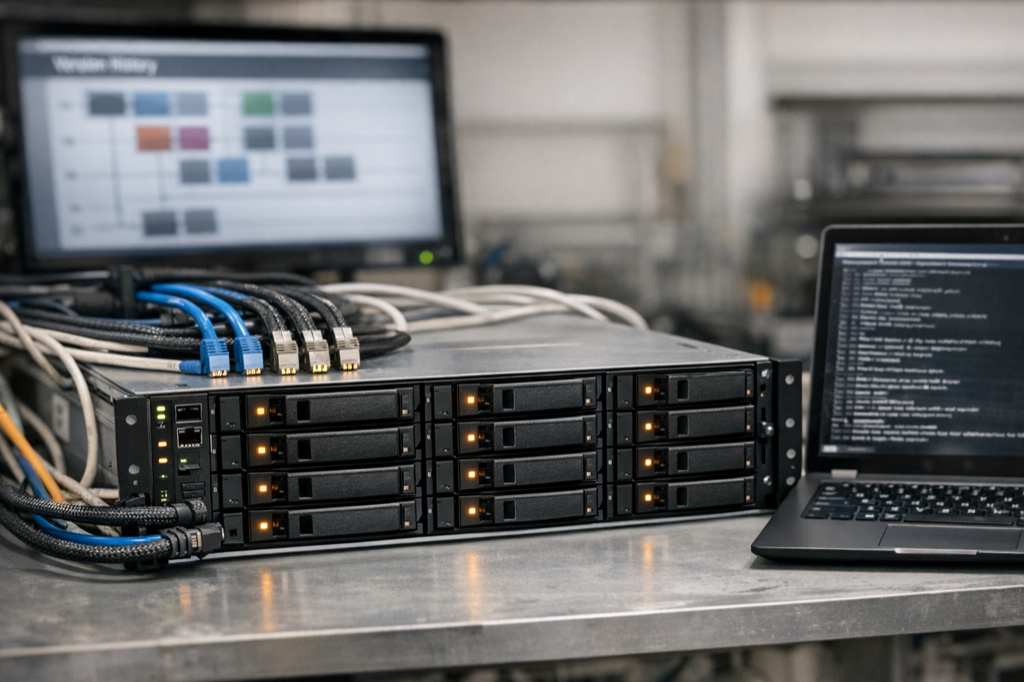
Dataset and model versioning on checksummed local storage with reproducible remotes for every build team.
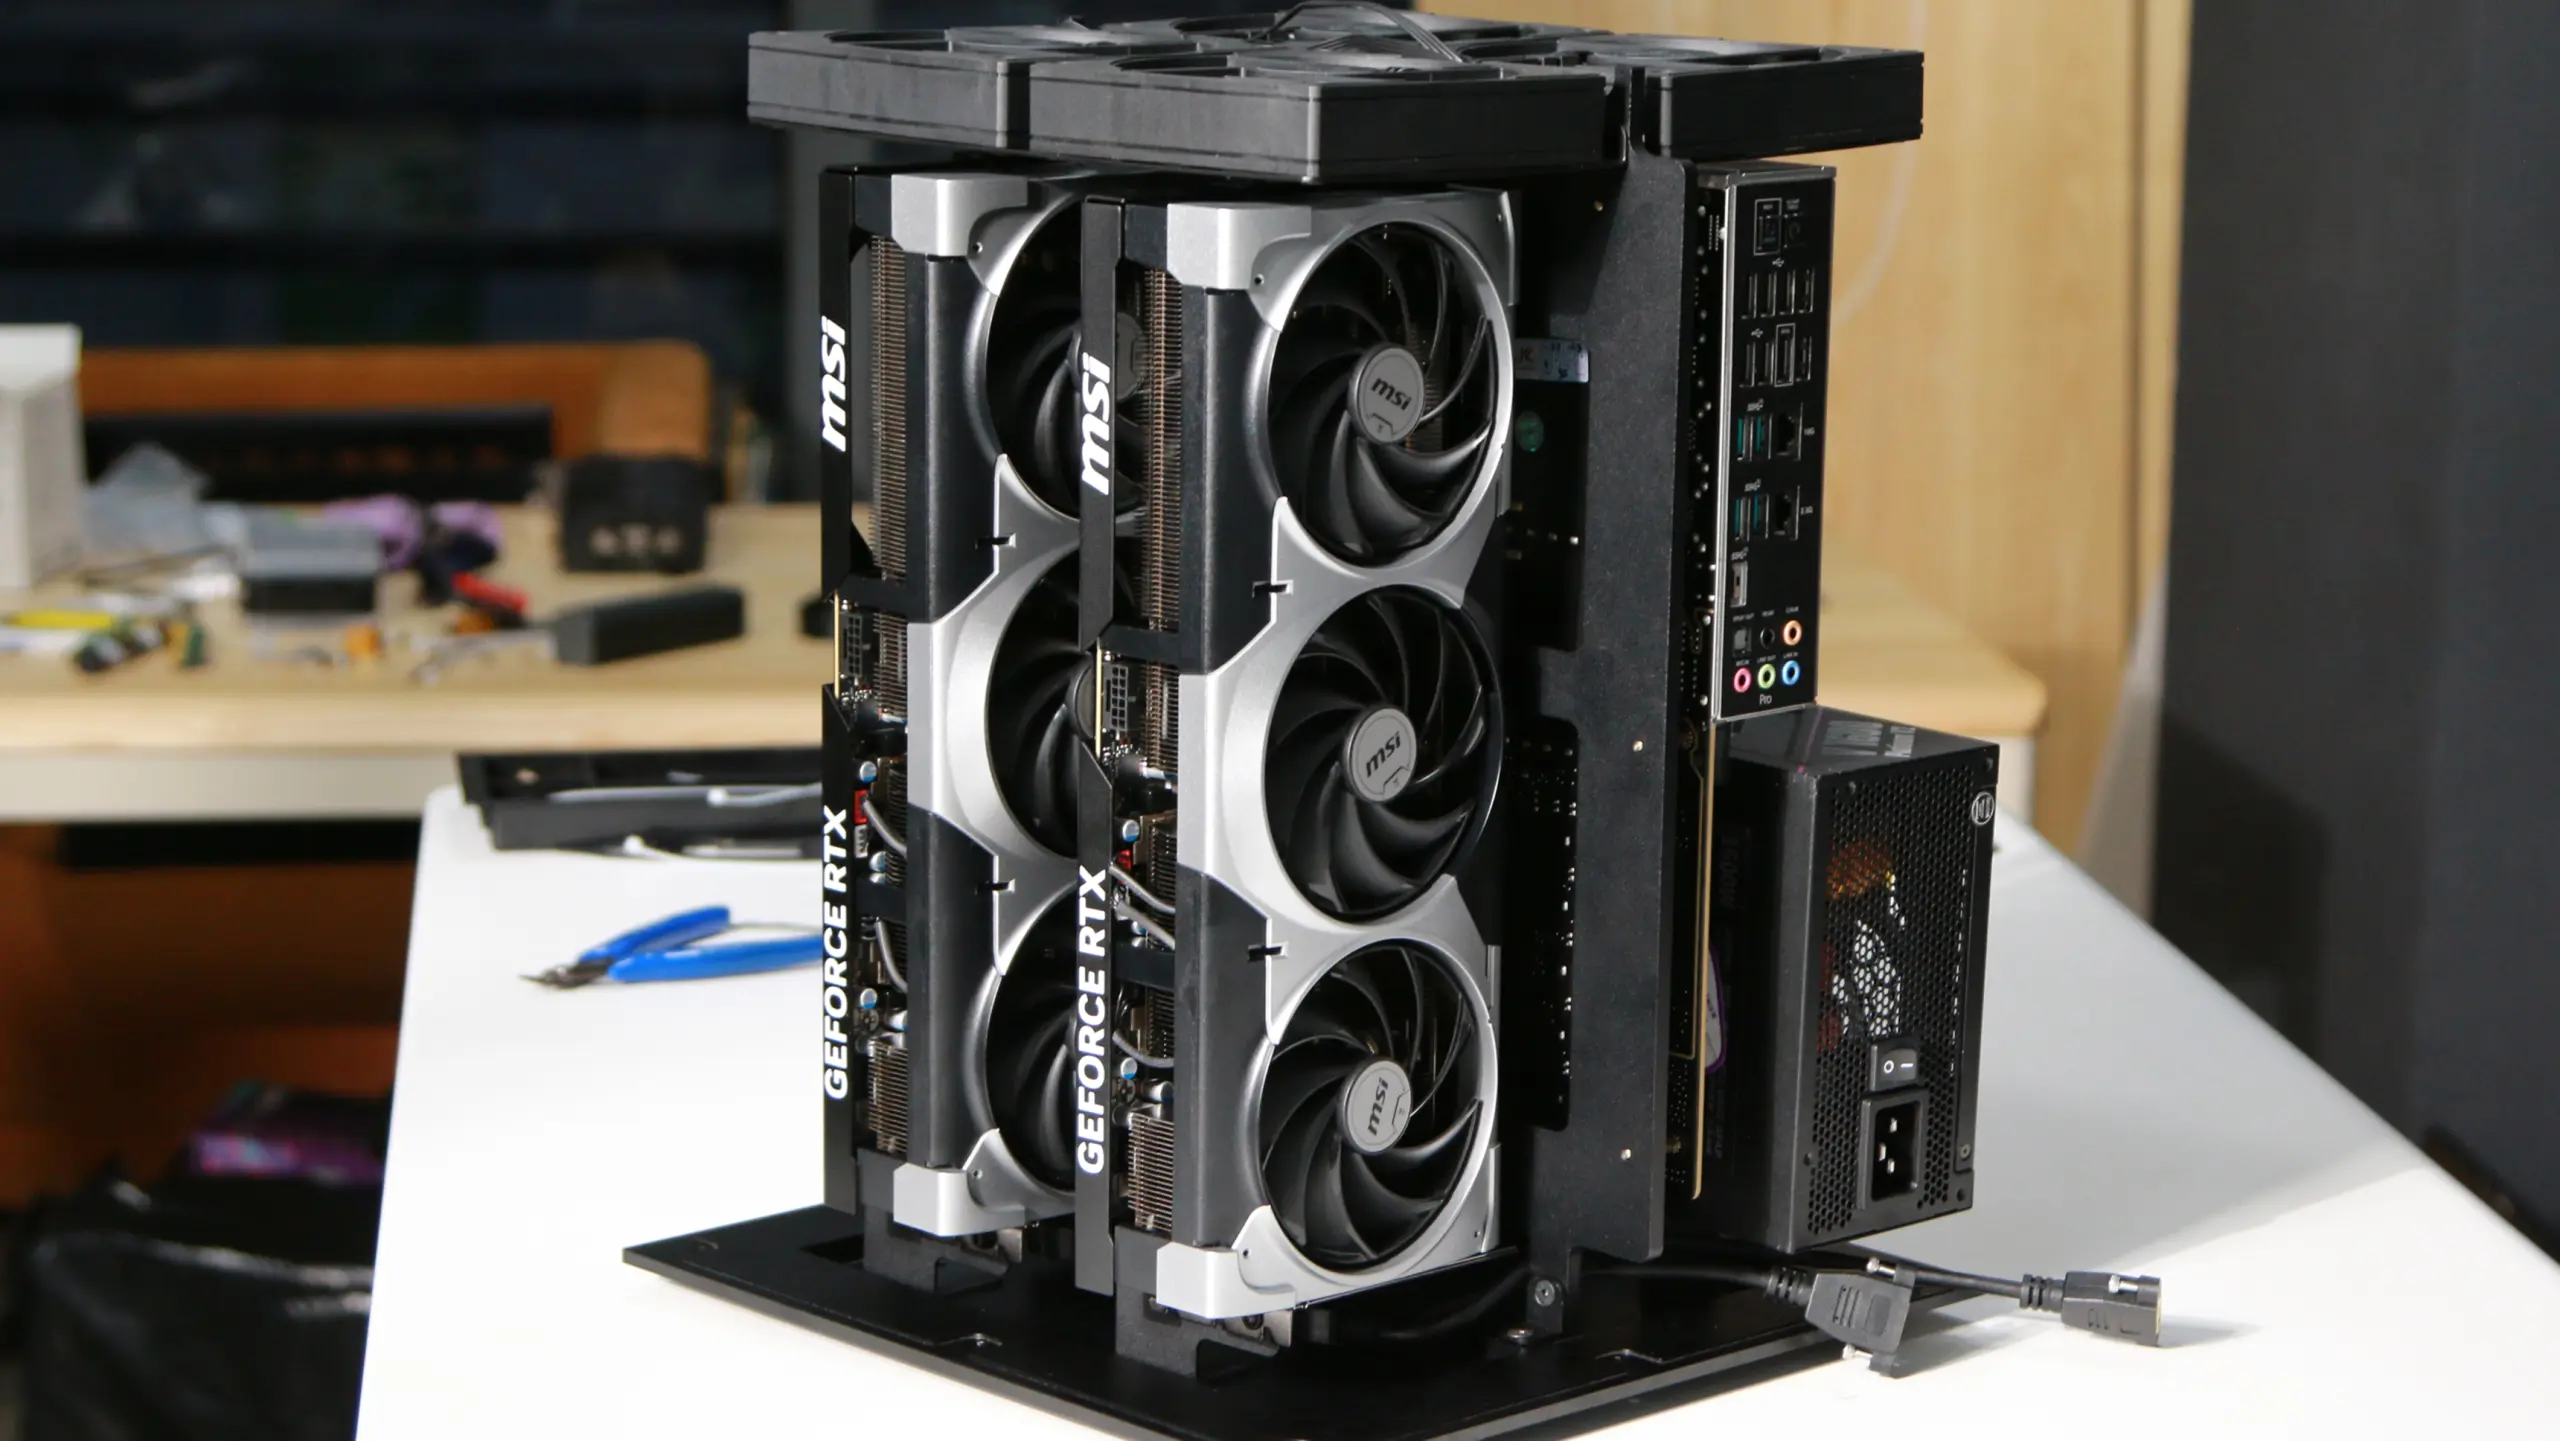
A local multi-GPU workstation for robot learning, simulation, vision, fine-tuning, and private inference.
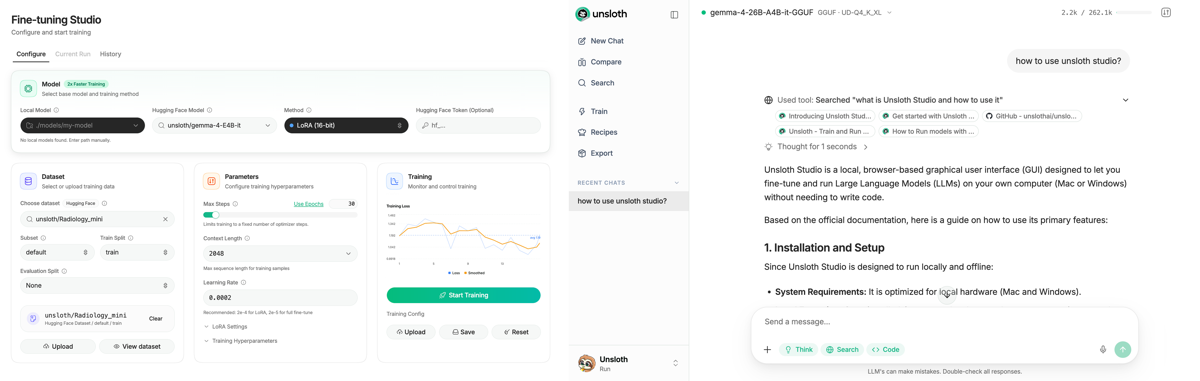
A documented local fine-tuning lane for small language and vision-language models using the lab GPU queue.
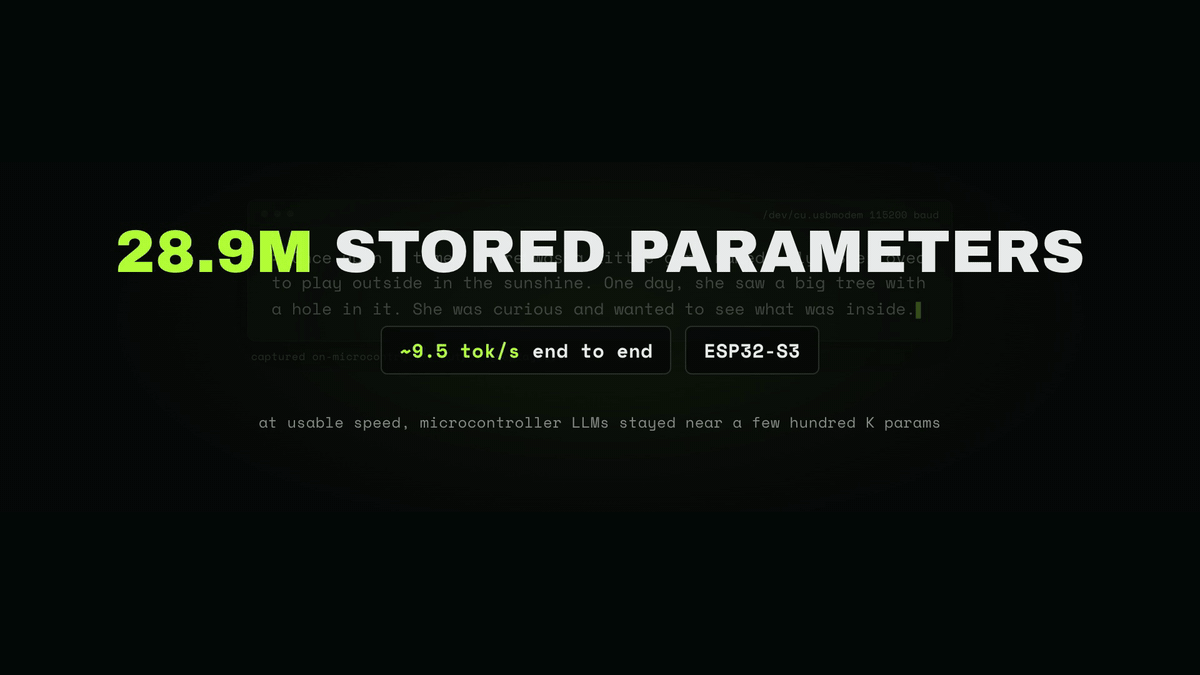
A research reproduction of a 28.9M stored-parameter TinyStories model running fully offline on an ESP32-S3 N16R8 at roughly 9.5 tokens per second.
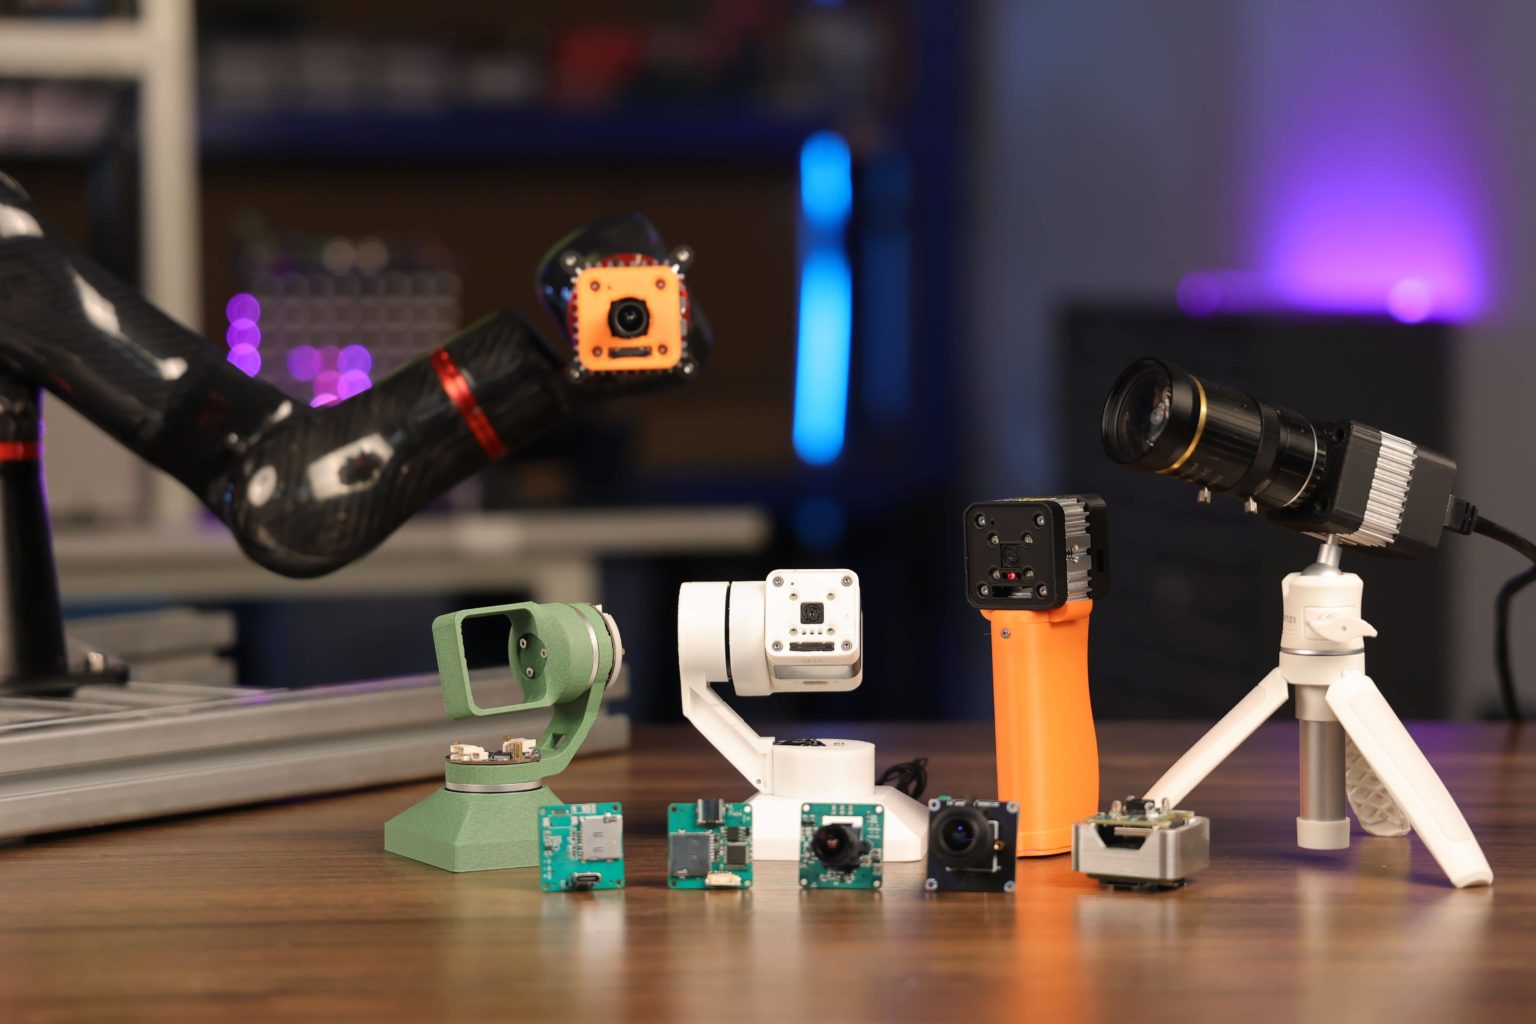
An open modular RISC-V AI camera for local object detection, robot perception, low-code vision pipelines, and controllable camera experiments.
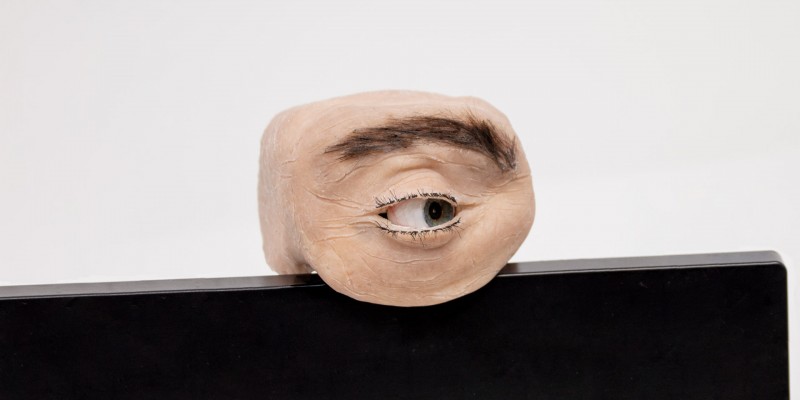
An open anthropomorphic webcam with an actuated eye, eyelids, eyebrow, embedded camera, and six-servo motion for studying expressive sensing and visible privacy cues.
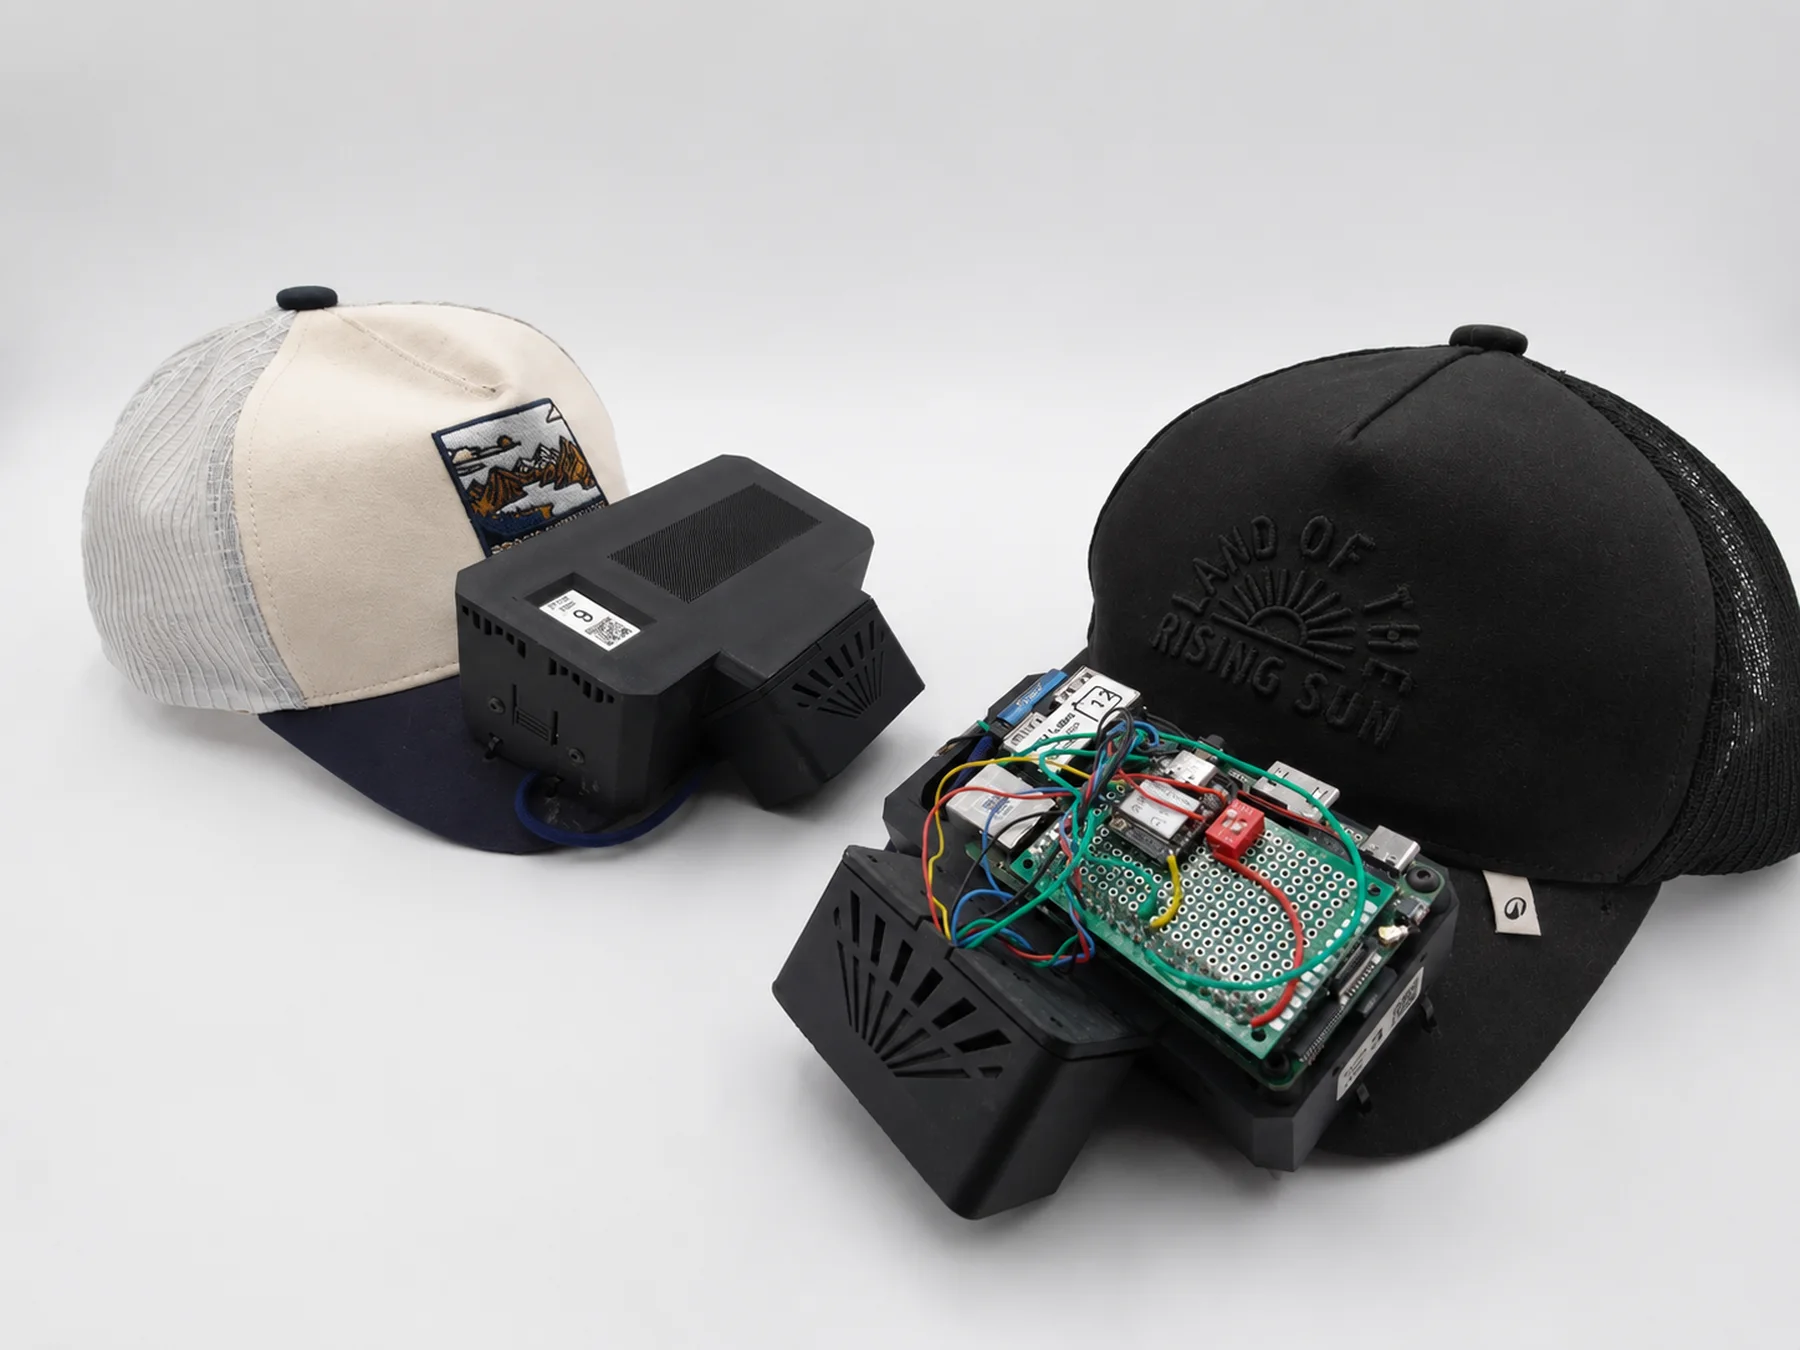
A published 280 g head-worn stereo-inertial capture rig combining synchronized global-shutter video, high-rate IMU data, and on-device H.264 recording for egocentric robotics datasets.
Paired low-cost arms for teleoperation, demonstration collection, imitation learning, and repeatable tutorials.
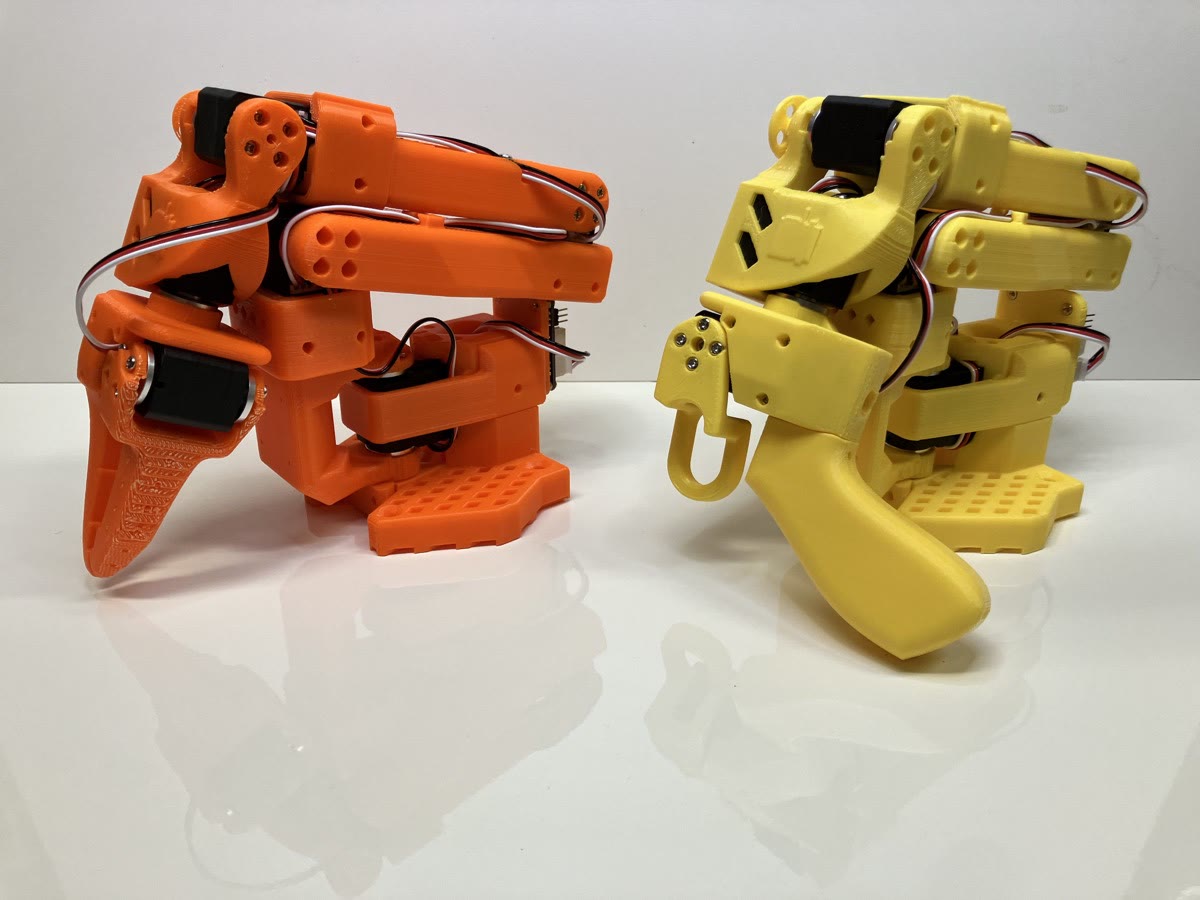
Open low-cost arm hardware designed as the practical companion to LeRobot data collection and imitation-learning experiments.
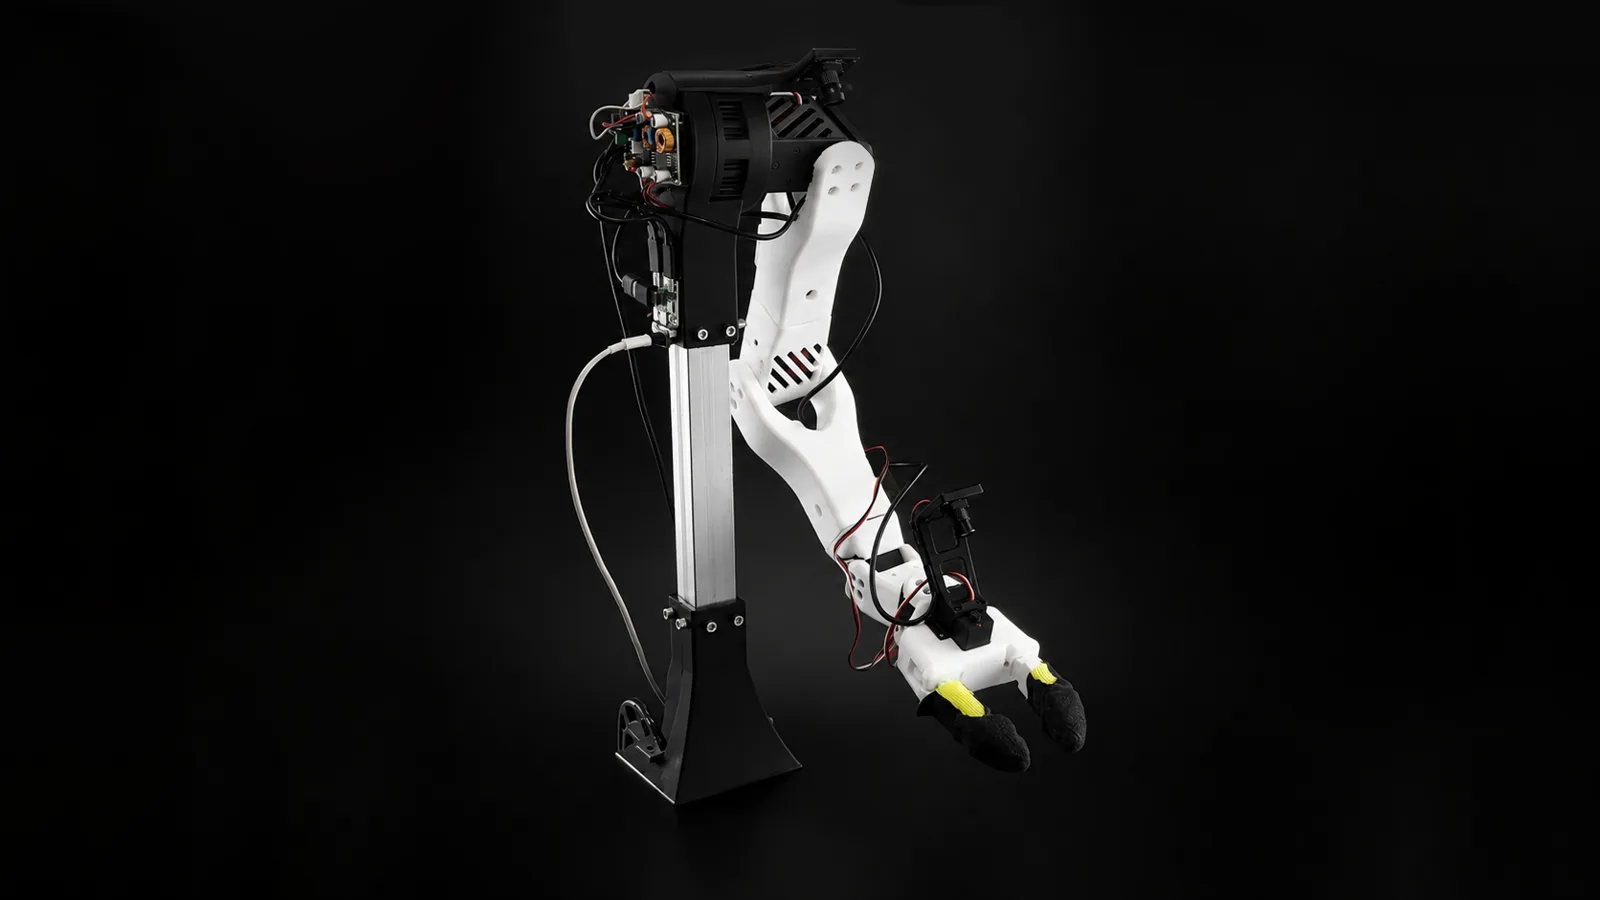
The Good Enough Manipulator: a practical open robot arm designed around accessible parts and reproducible assembly.
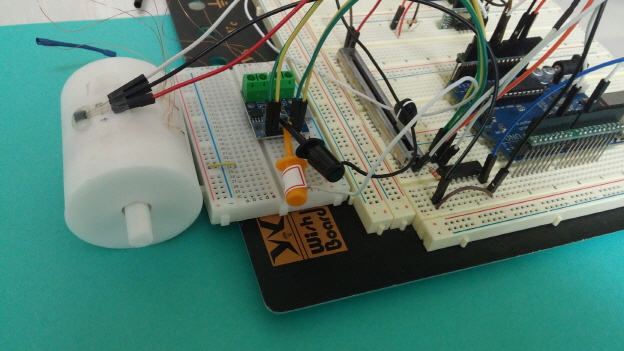
Open reference projects for designing, simulating, fabricating, and testing small electromagnetic actuators, anchored by a 3D-printed linear voice-coil motor.
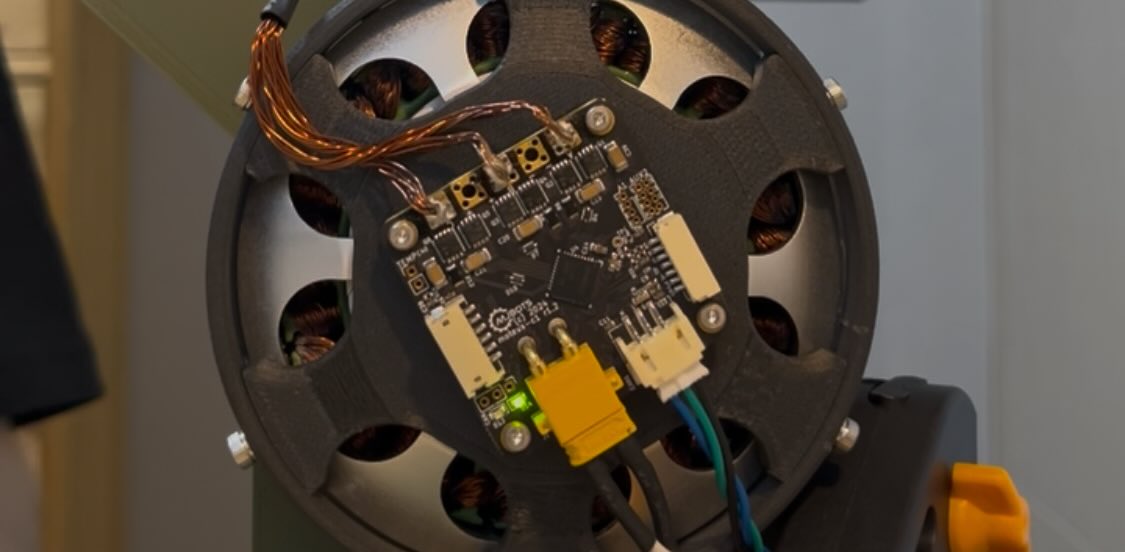
Seo Jin Jeong's experimental actuator combines a custom 8110 BLDC motor, 10:1 cycloidal reducer, and moteus-c1 FOC control. CNC aluminum and printed mechanics; the author flags rigidity and torque-density limits in this first prototype.
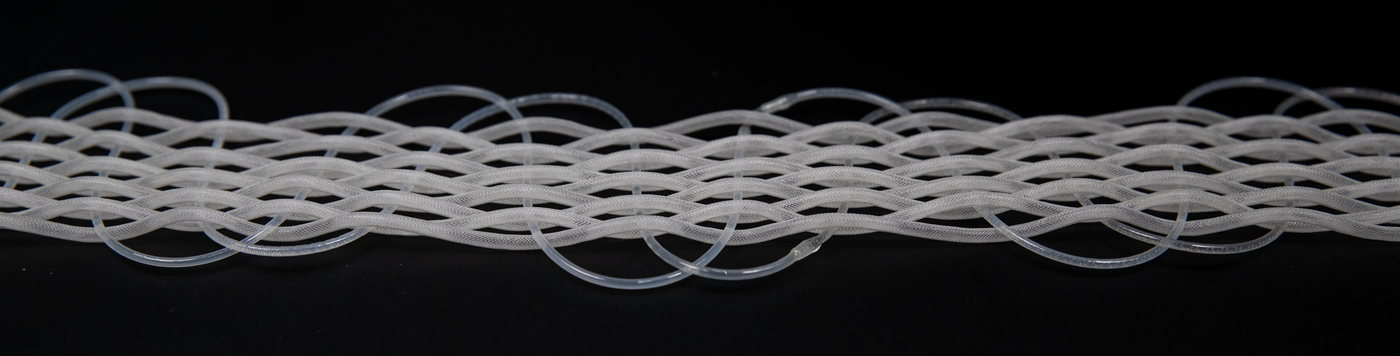
Millimeter-scale artificial muscles that pair embedded electrohydrodynamic pumps with thin McKibben actuators for silent, compliant, modular linear actuation.
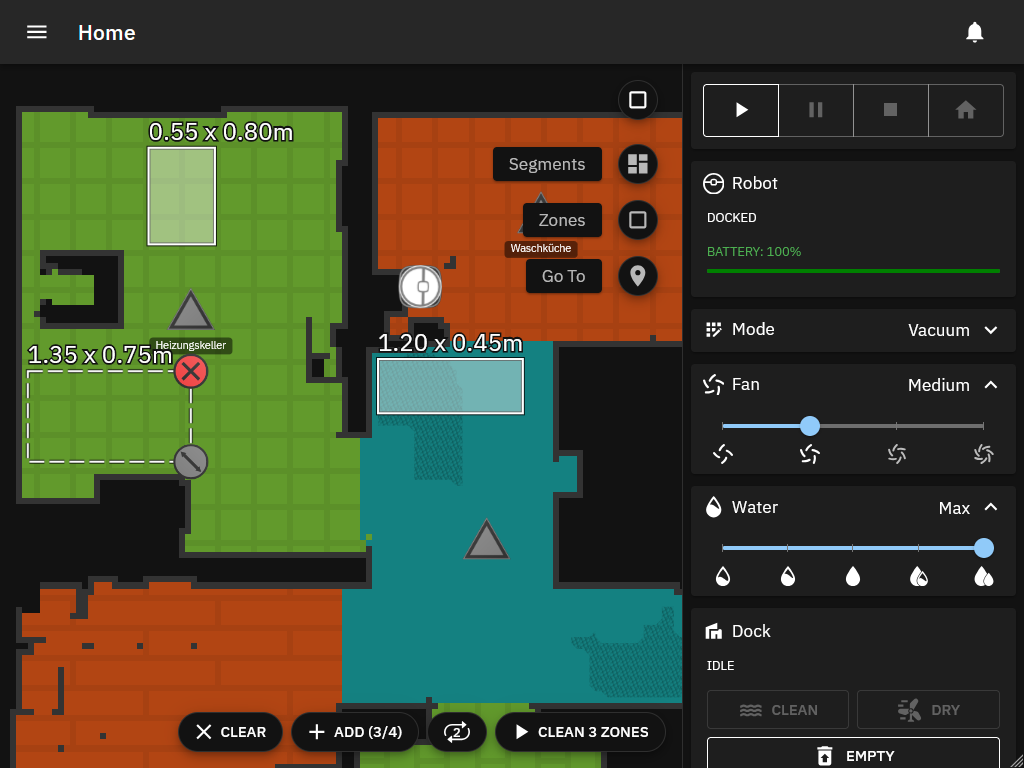
A cloud-free robot vacuum software stack for studying navigation, maps, telemetry, and local autonomy.
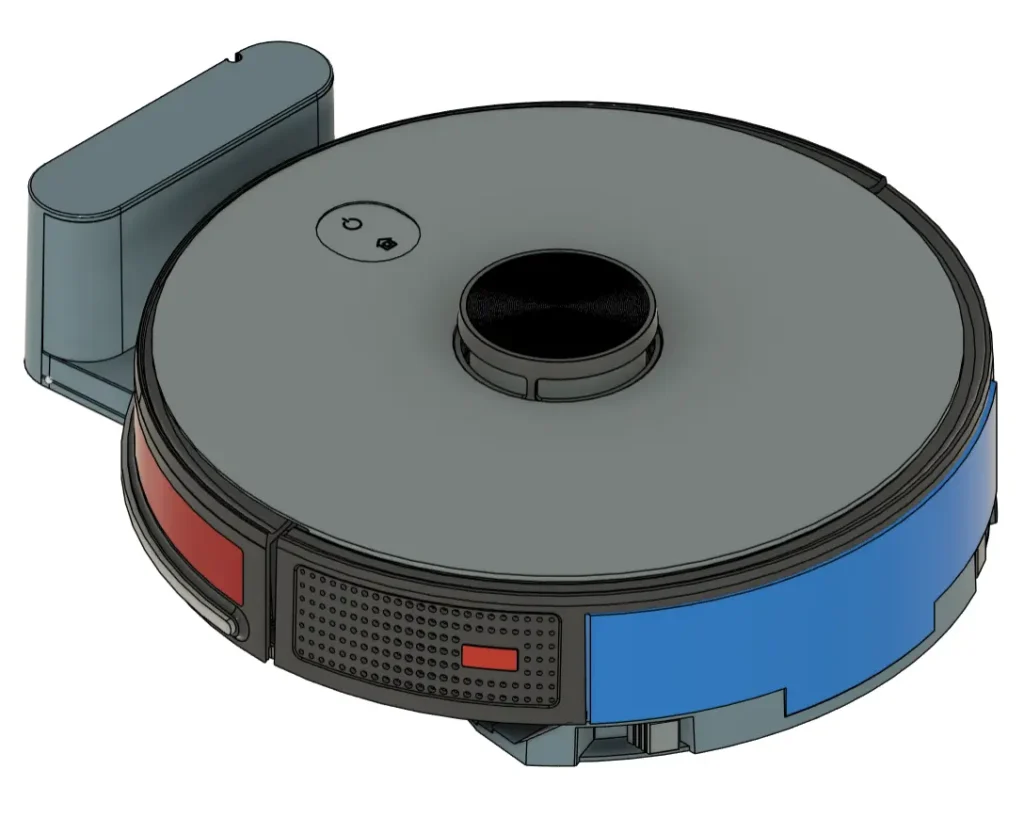
A fully open DIY robot vacuum using Raspberry Pi, ROS 2, LiDAR, ESP32 or Arduino control, and a printed chassis.
An open-source RTK robotic mower that makes outdoor navigation, safety, and power systems inspectable.
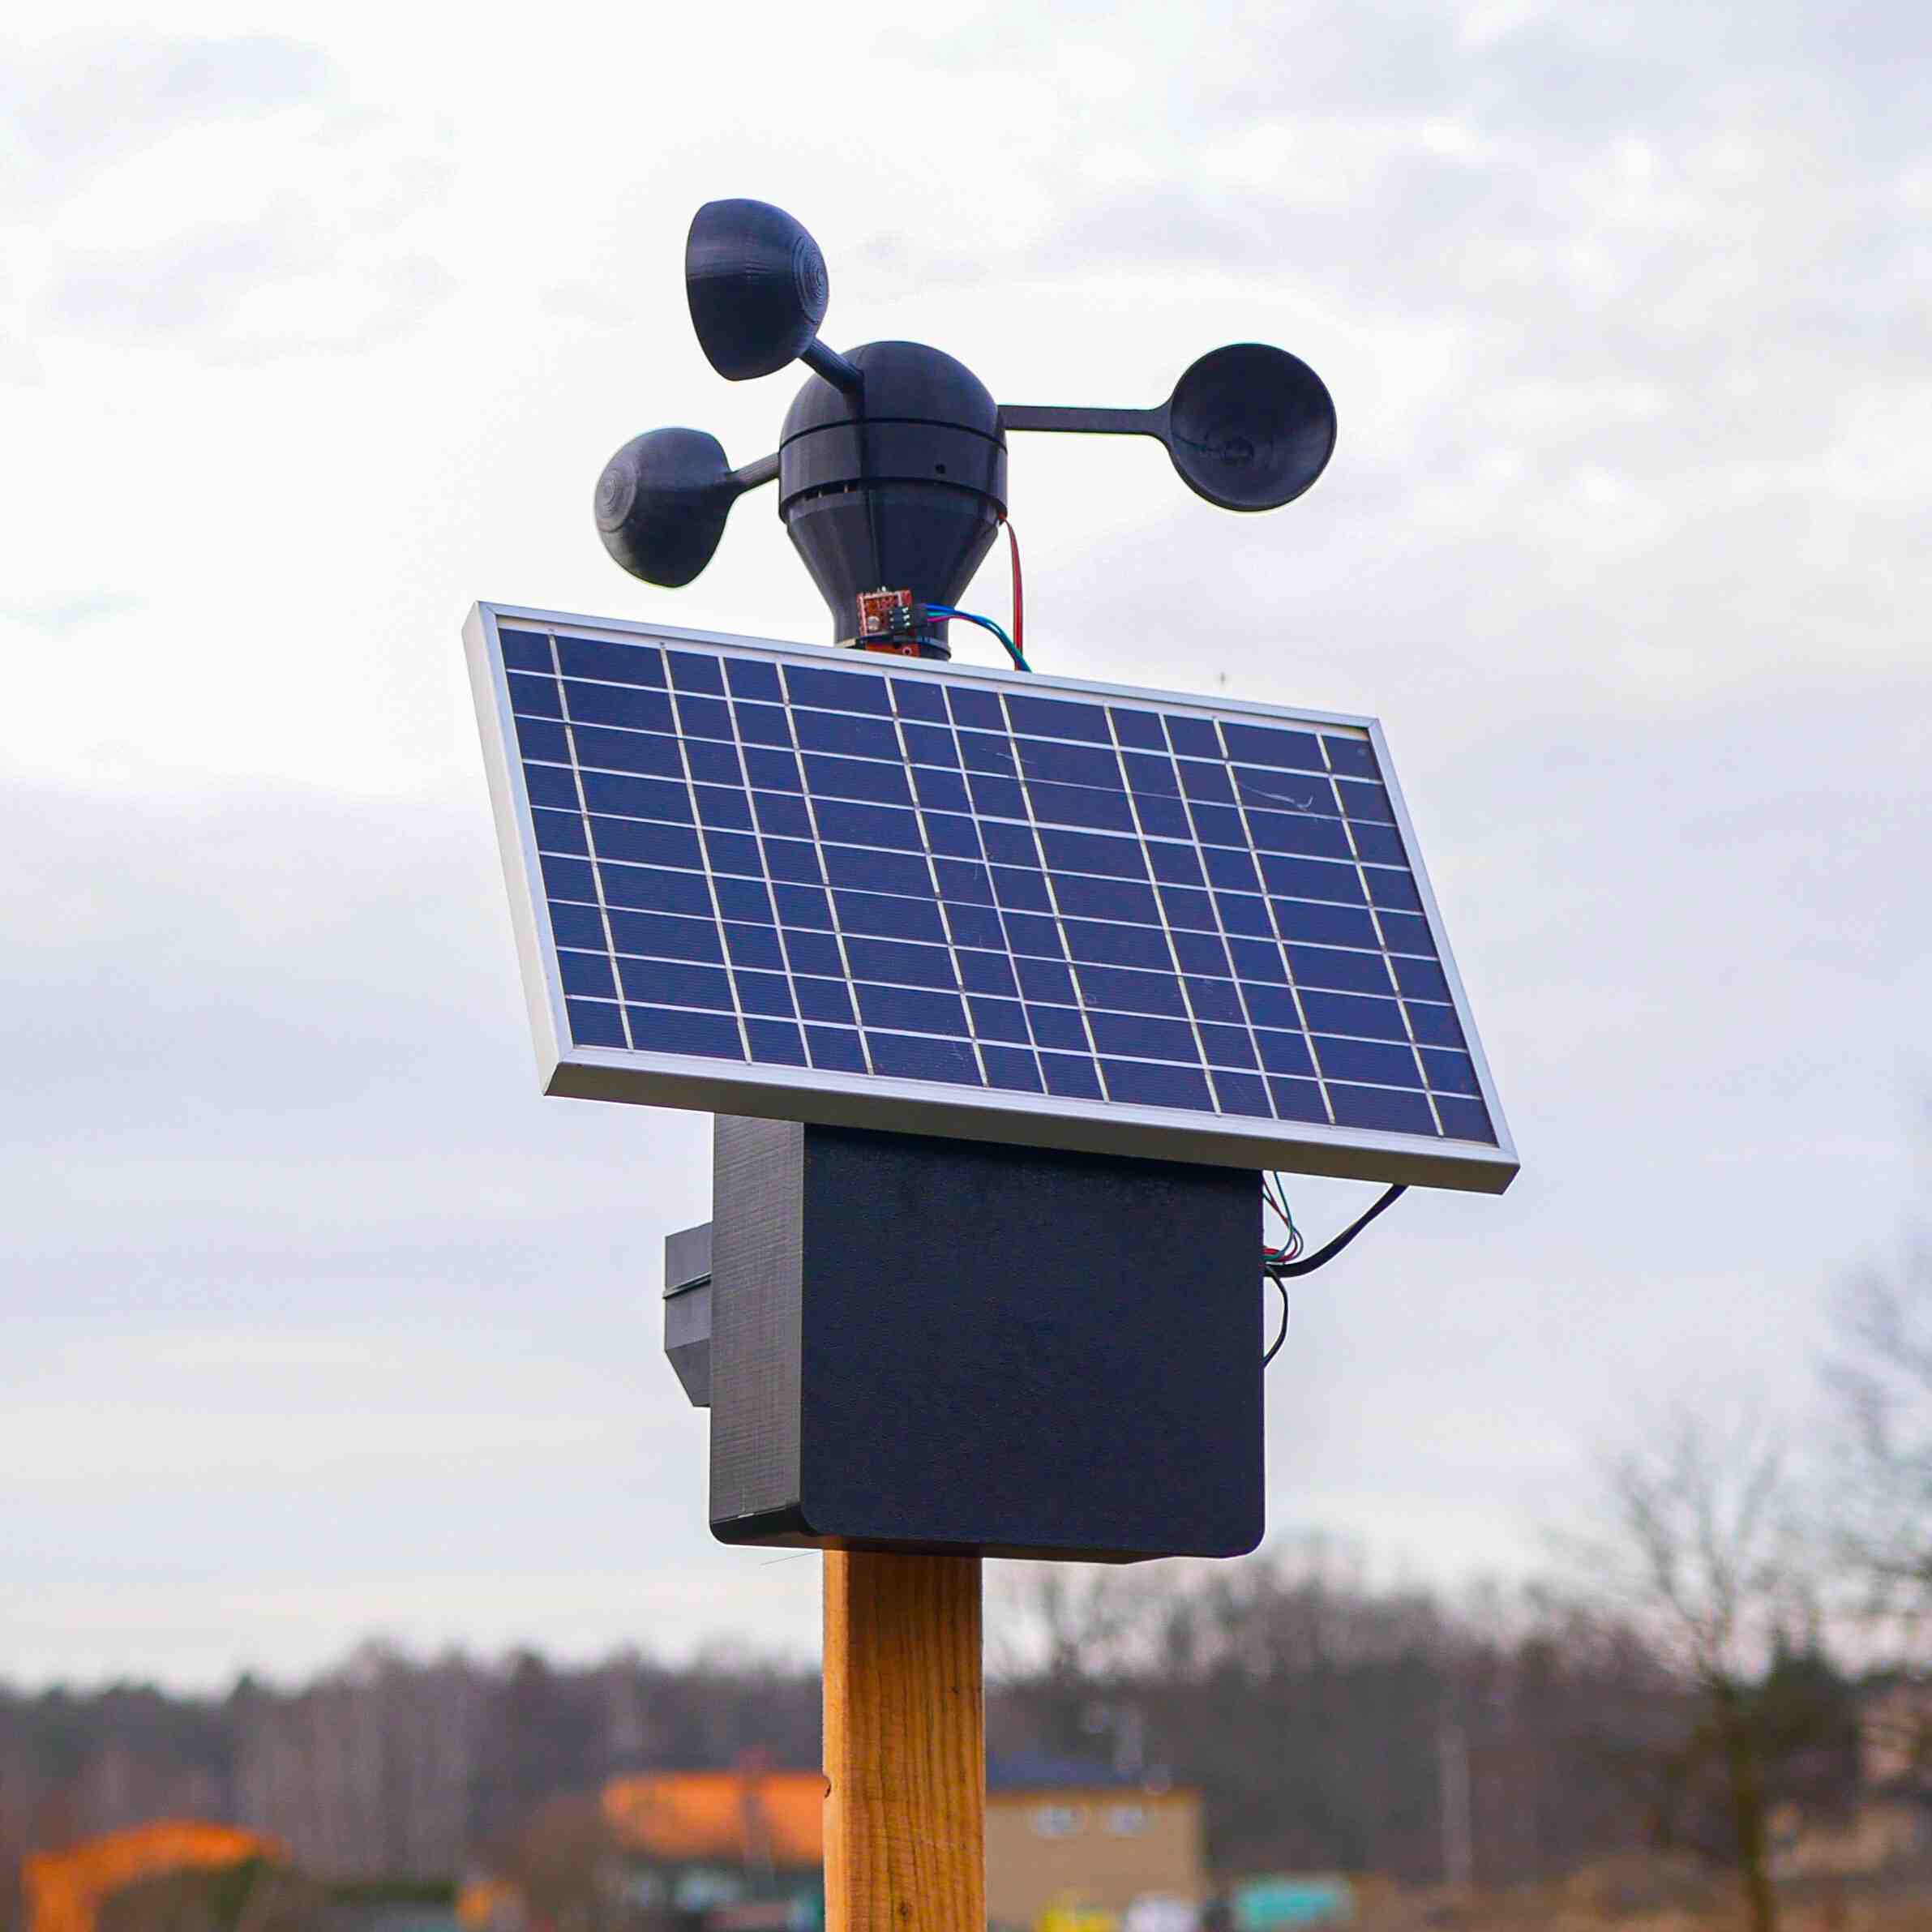
A solar-powered Raspberry Pi Pico W station that measures temperature, humidity, wind, pressure, light, rain, and battery state, then posts readings to a self-hosted Flask and MariaDB dashboard.
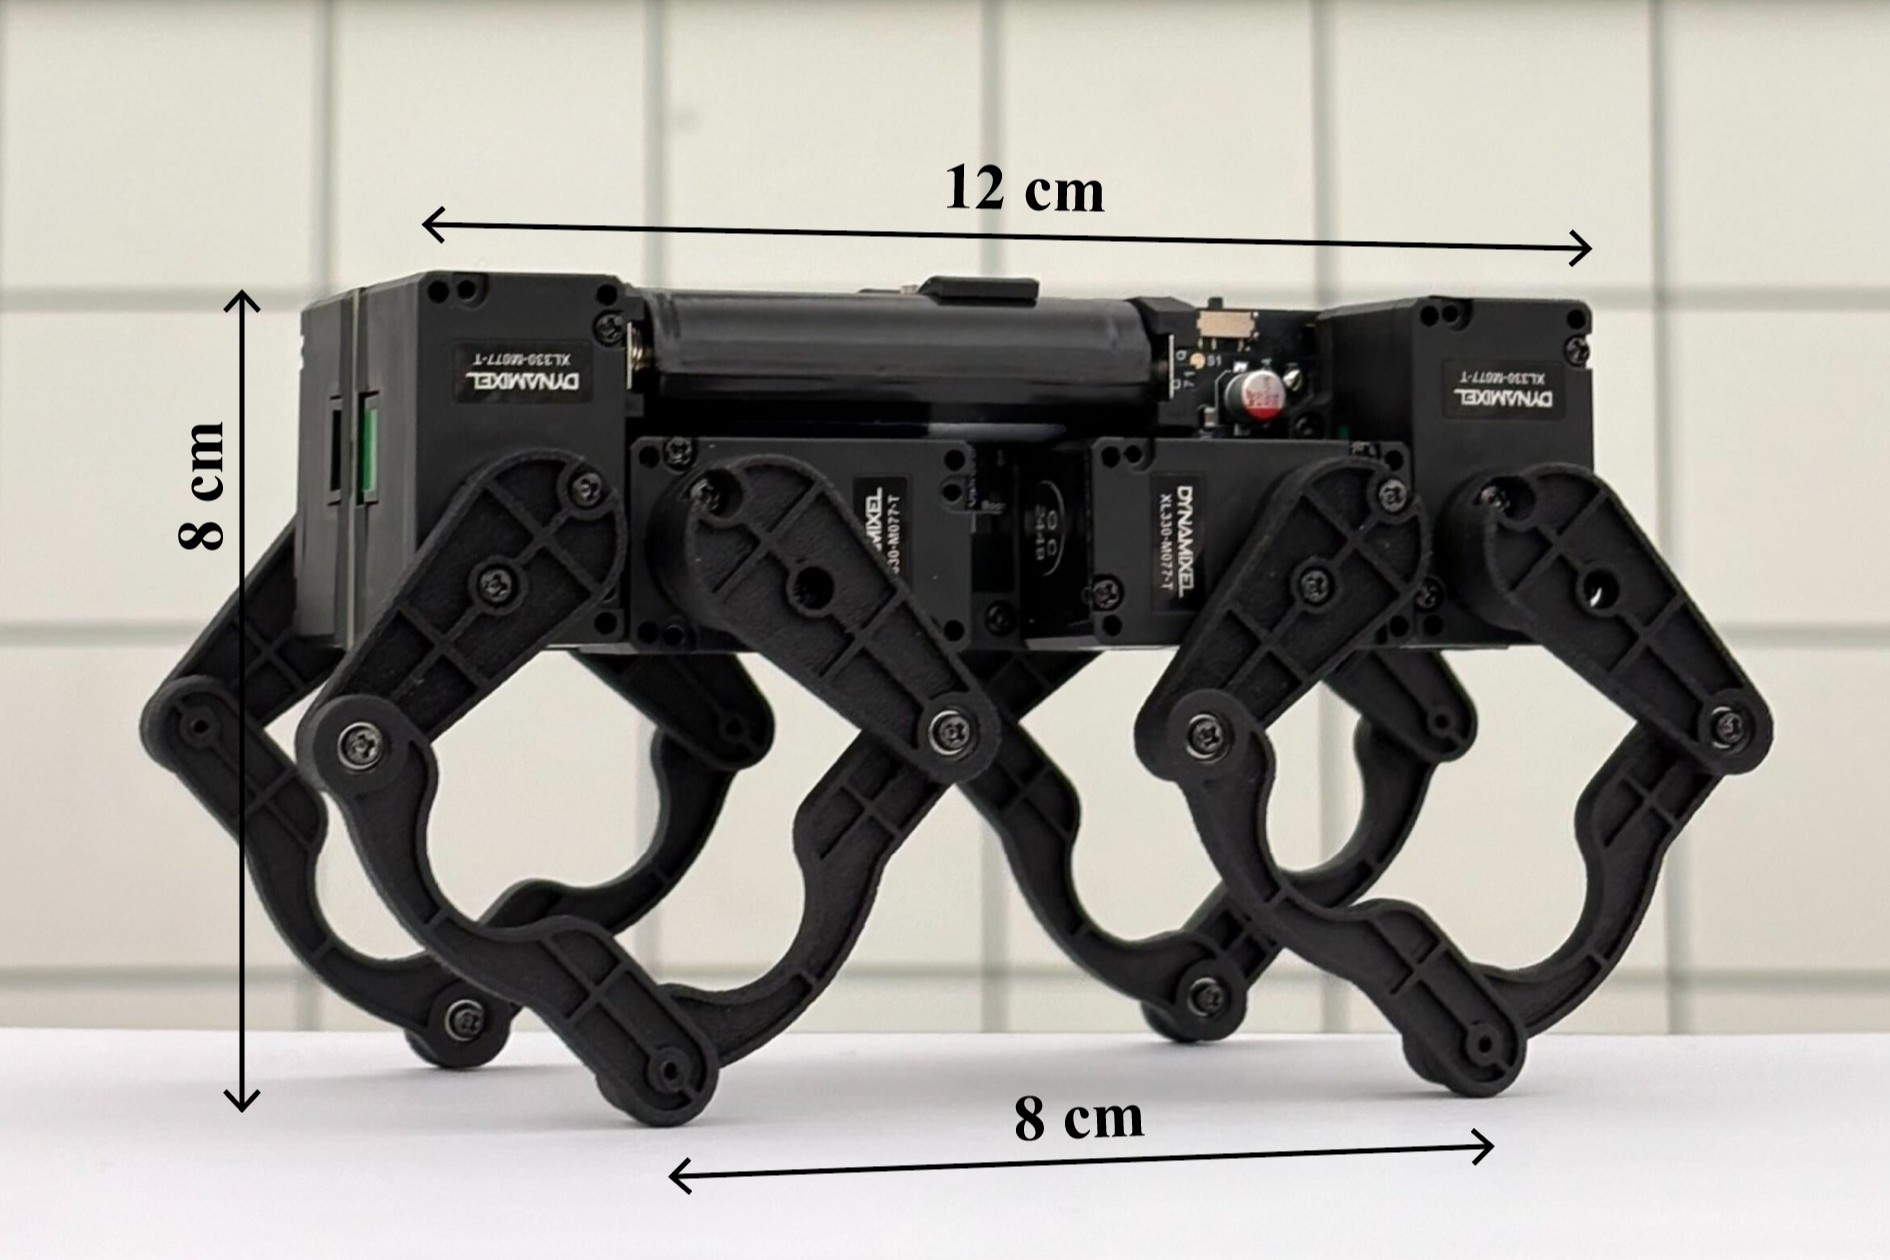
A palm-sized open quadruped with eight smart servos, a cable-free center PCB, wireless control, and printable mechanics for dynamic locomotion and swarm-robotics experiments.
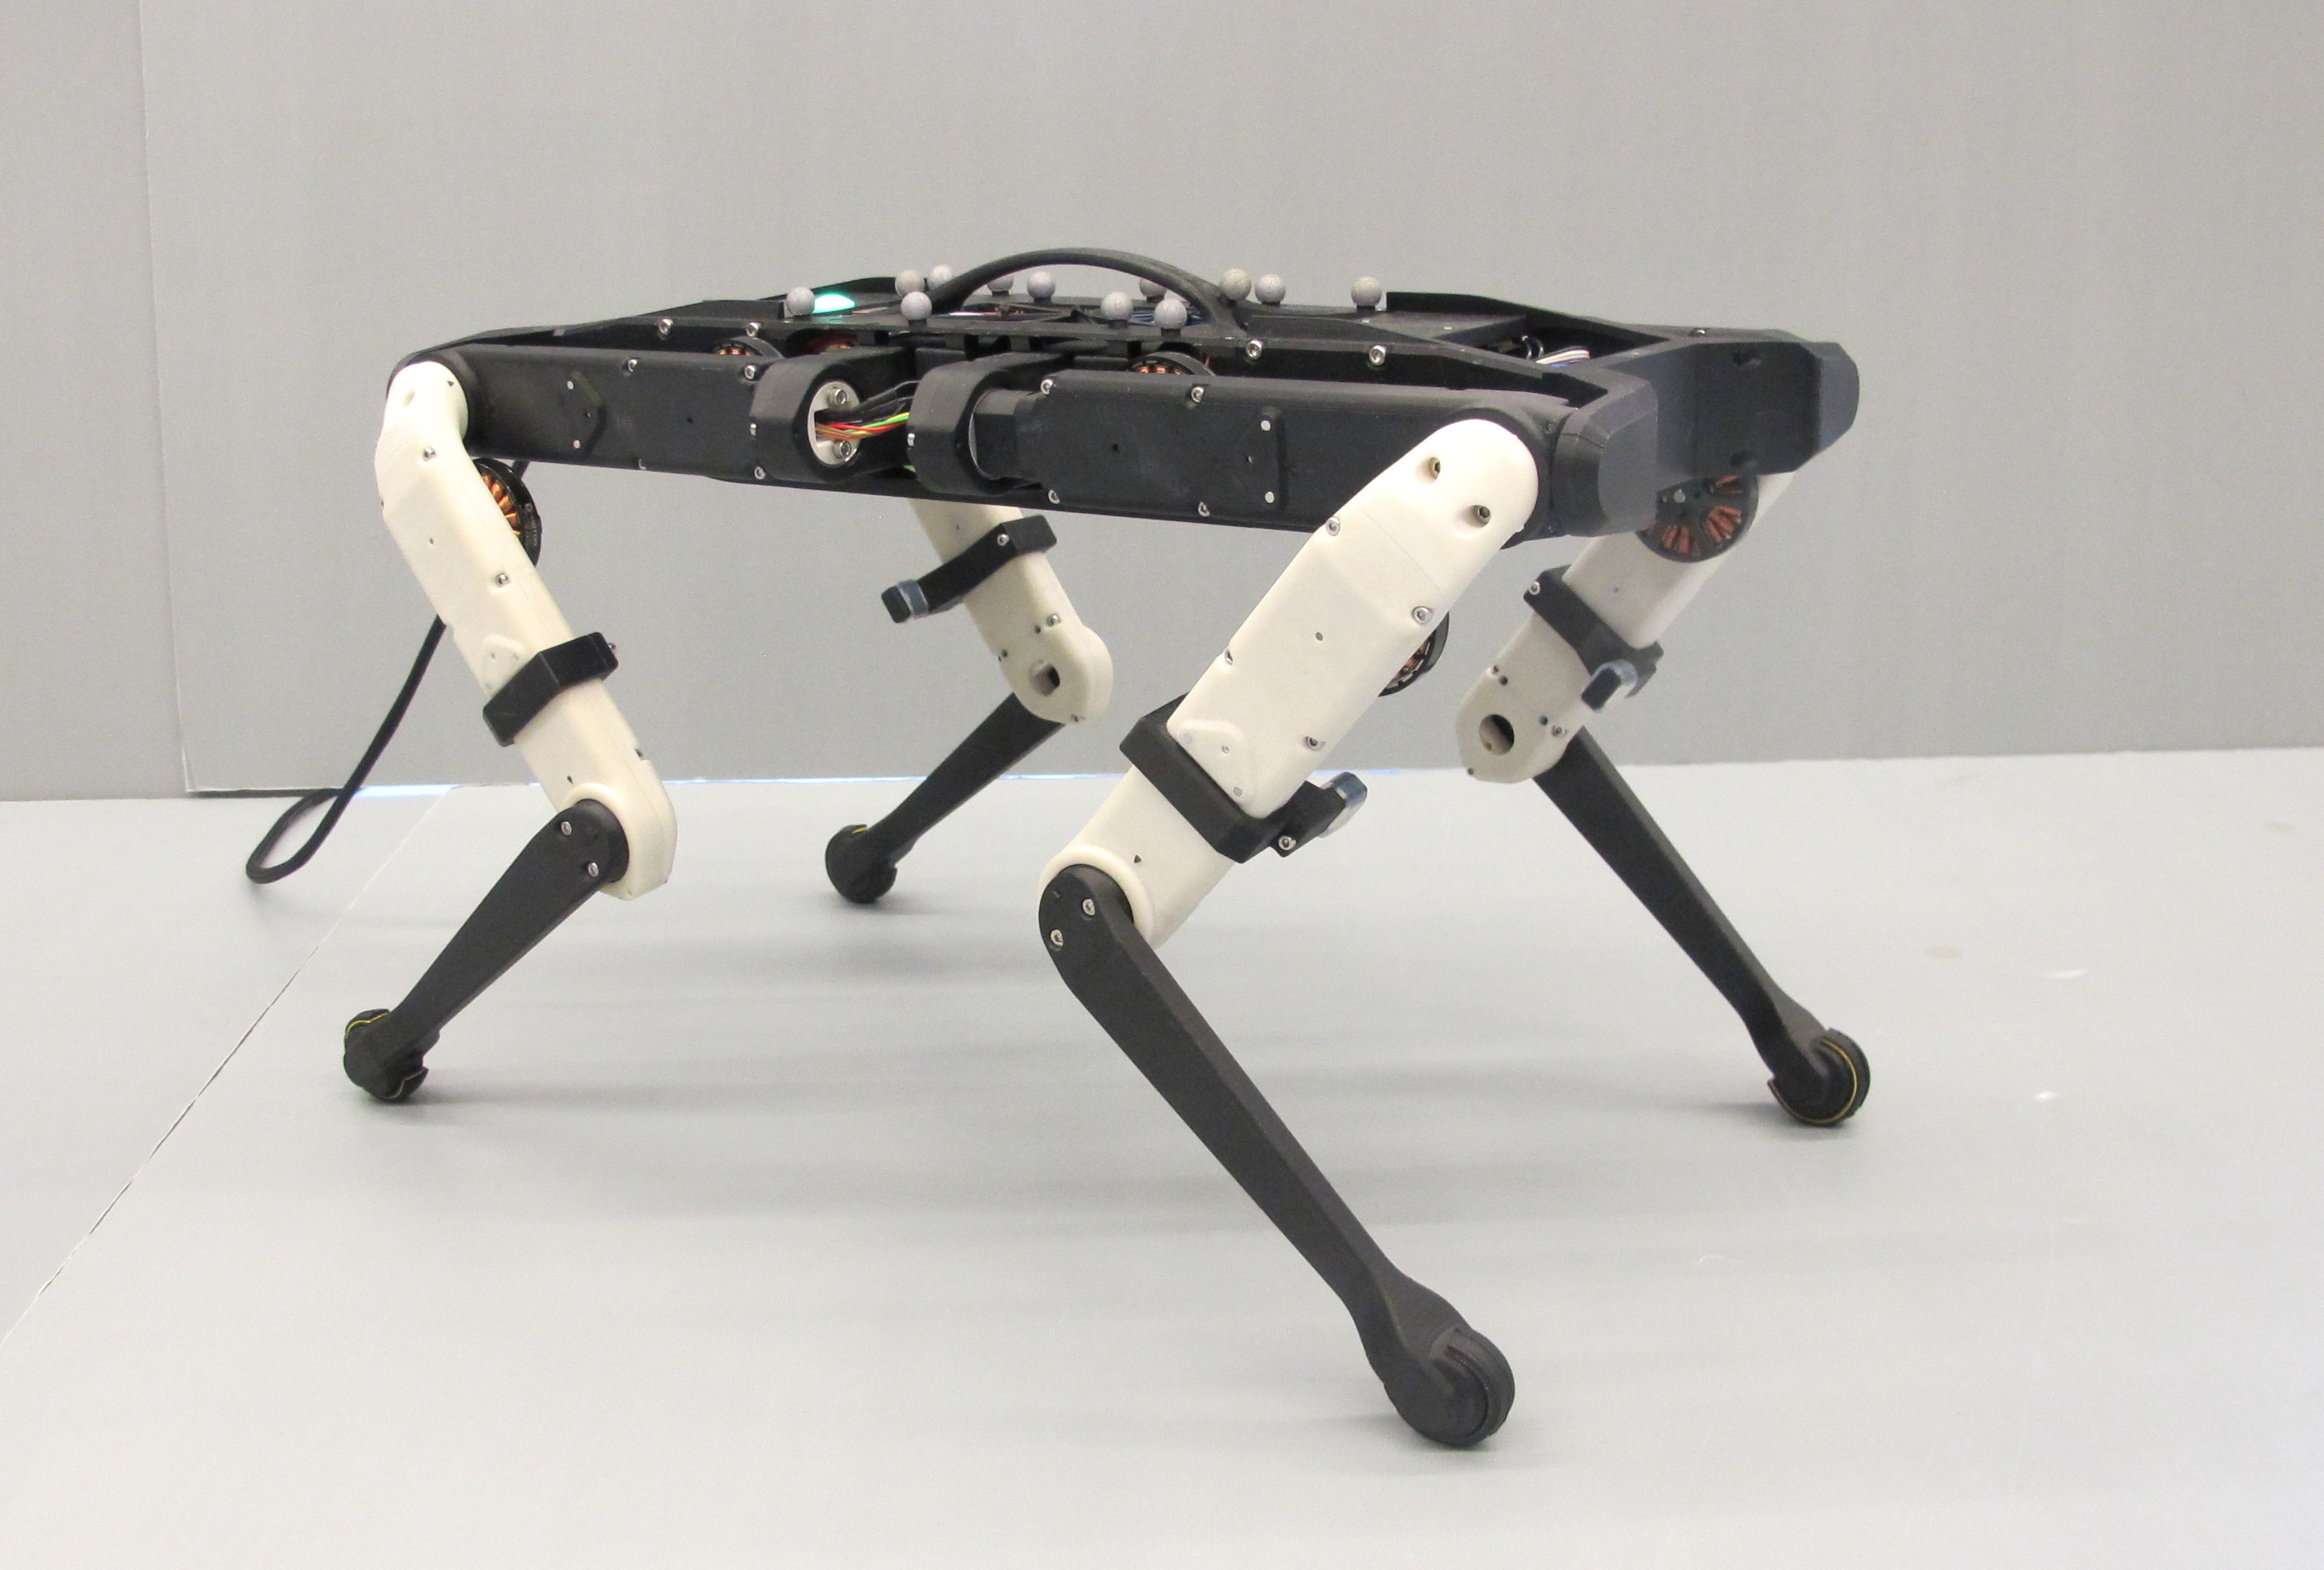
A 12-DoF torque-controlled quadruped built from modular brushless belt-drive actuators, custom motor-control electronics, an IMU, and predominantly printed mechanics.
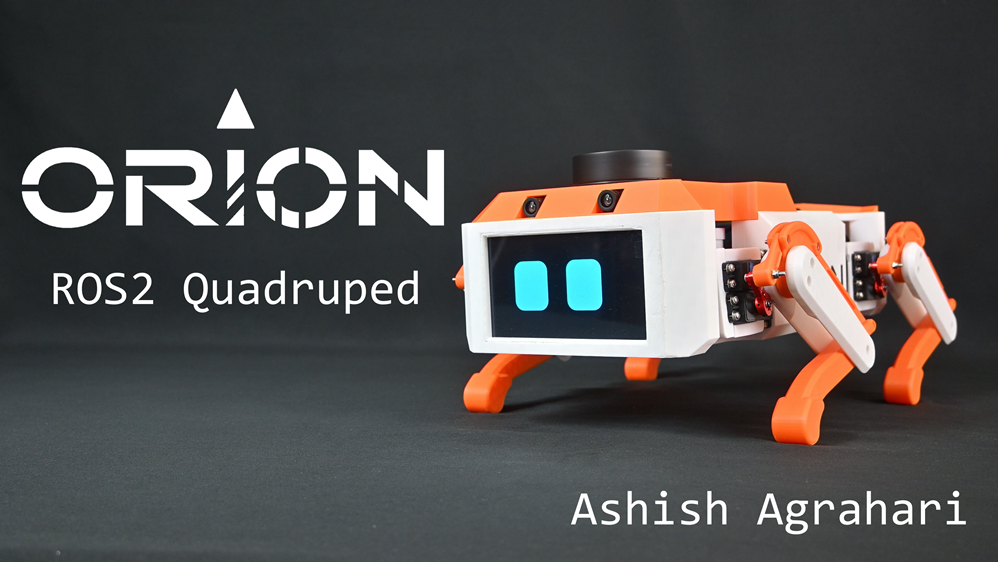
A custom 12-DoF ROS 2 quadruped coupling Jetson Orin Nano perception and Nav2 autonomy with STM32F401 FreeRTOS gait control, SolidWorks mechanics, and KiCad control and power boards.
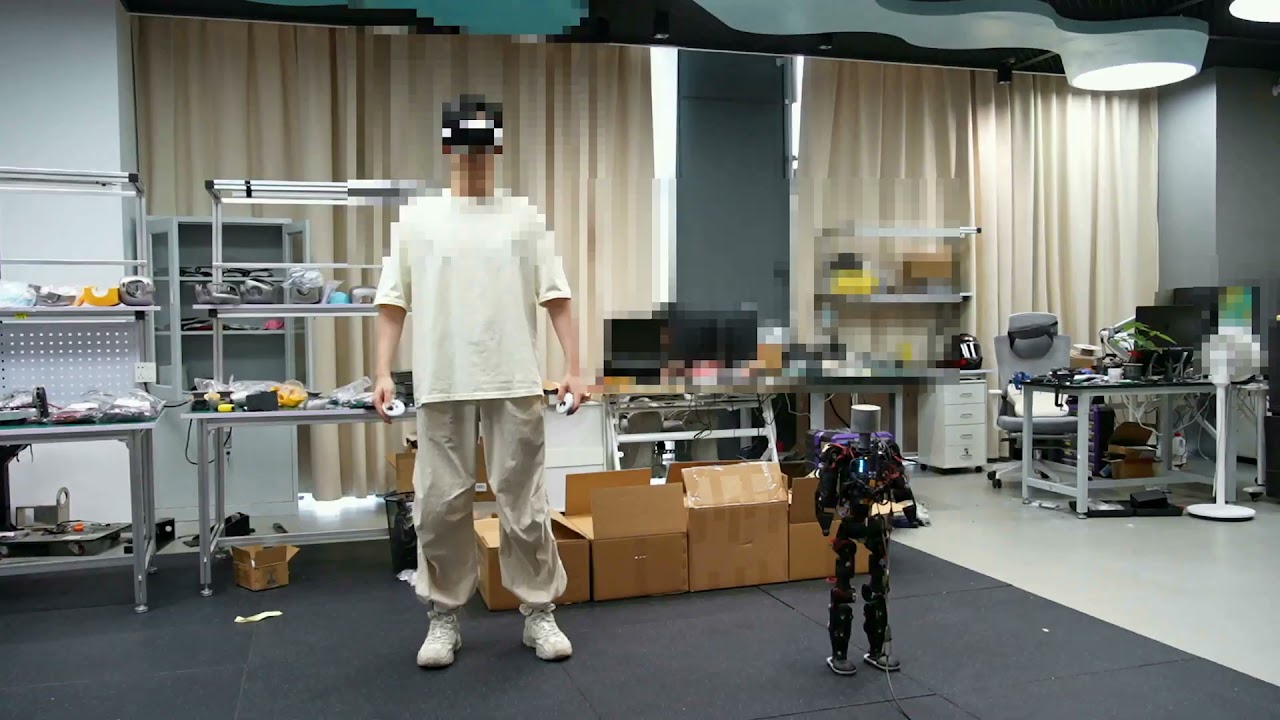
An 80 cm, 12.5 kg humanoid with 21 active DoF exploring morphology-control co-design and whole-body motion. Submitted to CoRL 2026; complete BOM, electrical, and training resources are promised on acceptance.
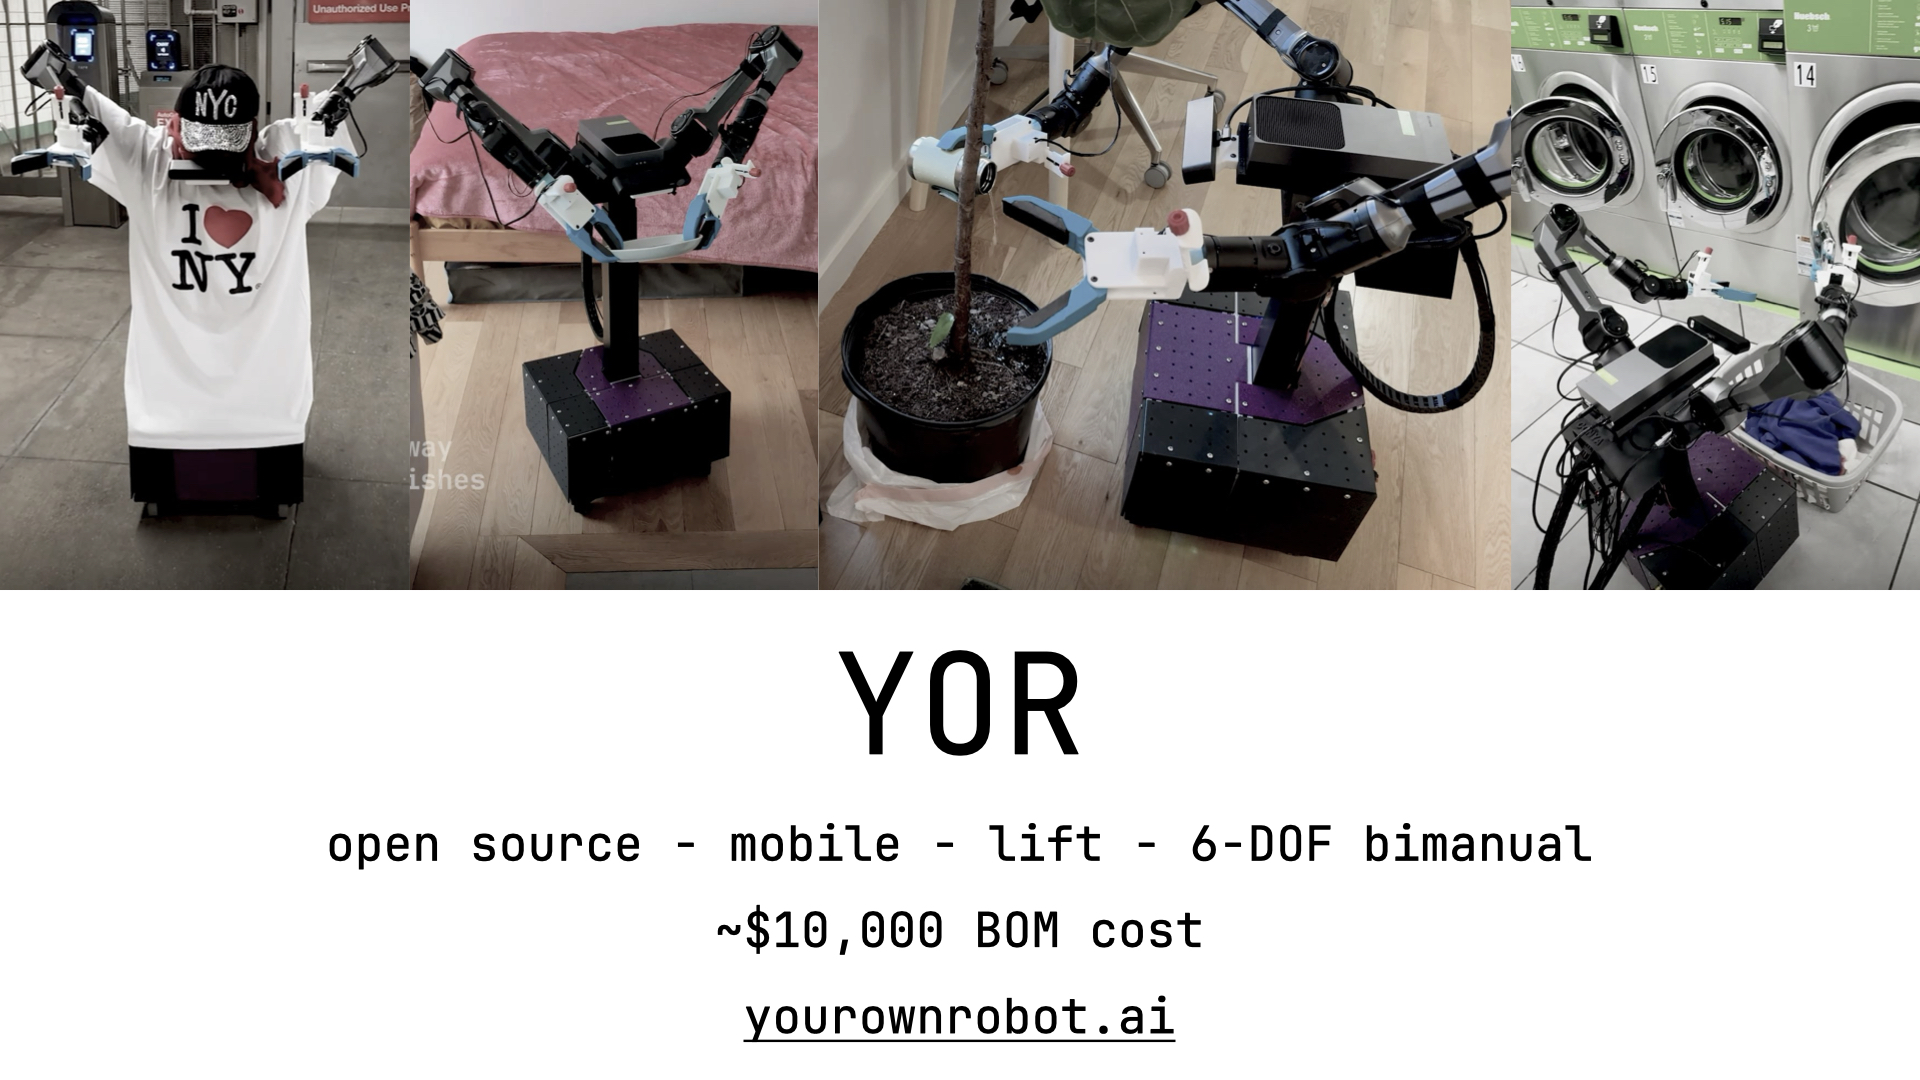
A fully open-source mobile manipulator with an omnidirectional base, adjustable lift, and two compliant 6-DoF arms for bimanual household-task research.
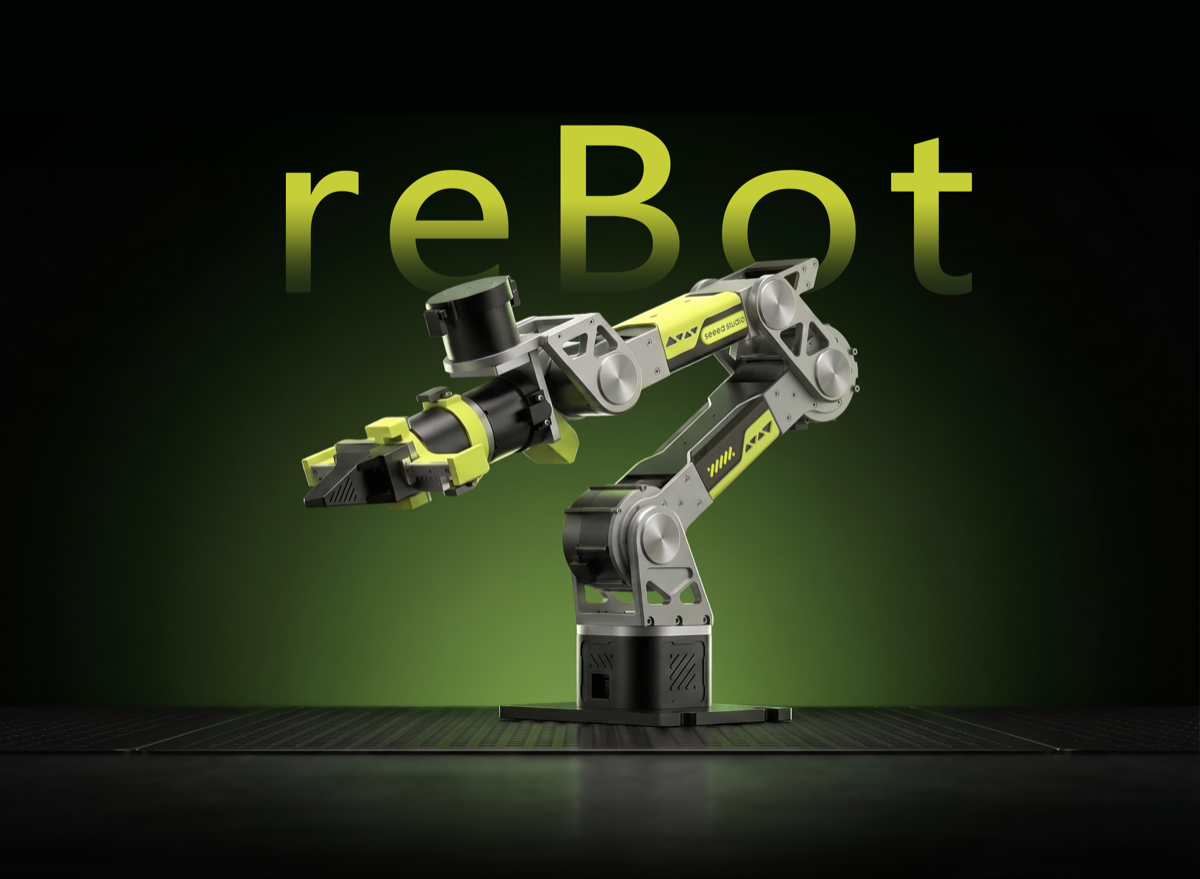
A compact development arm for manipulation software, perception experiments, and low-risk bench work.
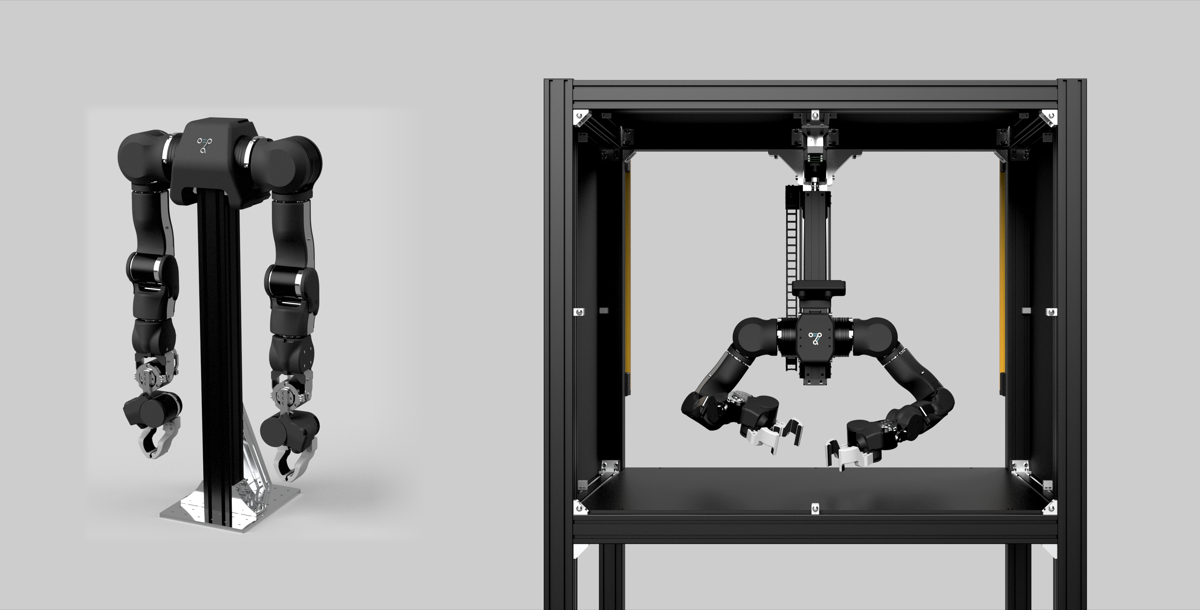
An open bimanual platform for dexterous manipulation, teleoperation, and embodied AI research.
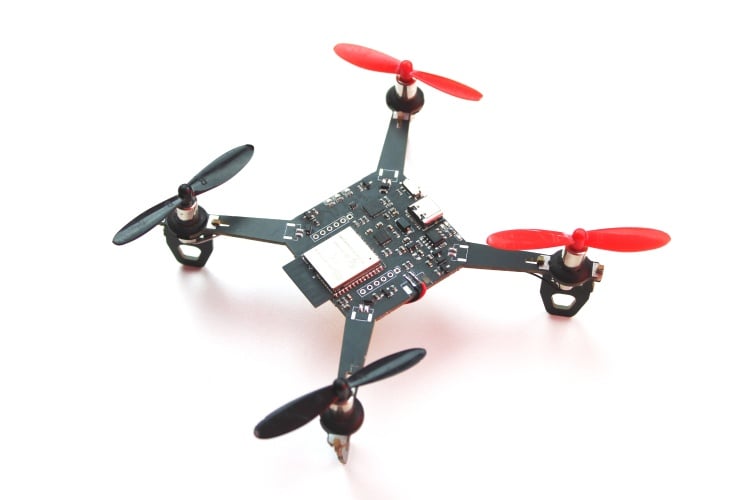
A compact Wi-Fi quadcopter built around an ESP32-WROOM, MPU6050, structural custom PCB, and four coreless motors for supervised flight-control and PID-tuning work.
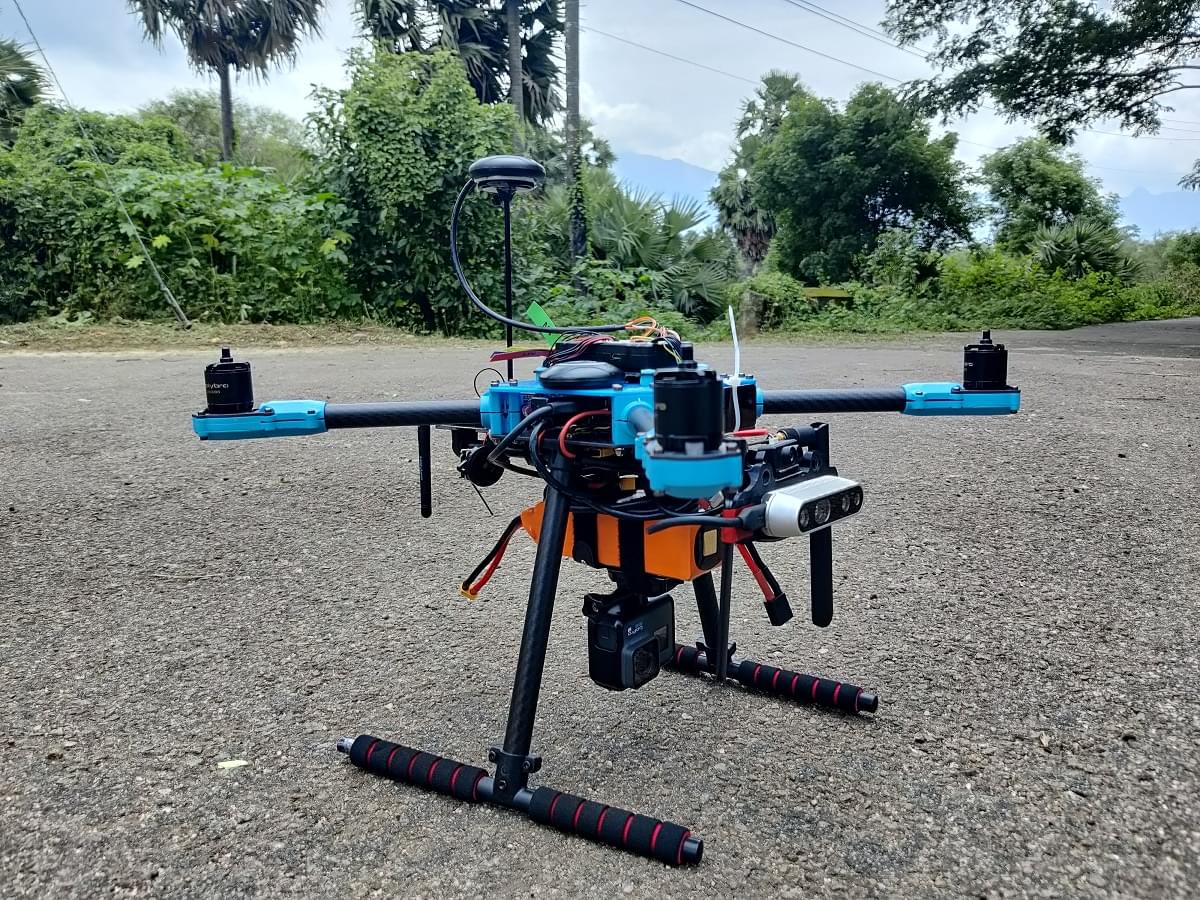
A flight-control and simulation stack with deliberate safety boundaries.
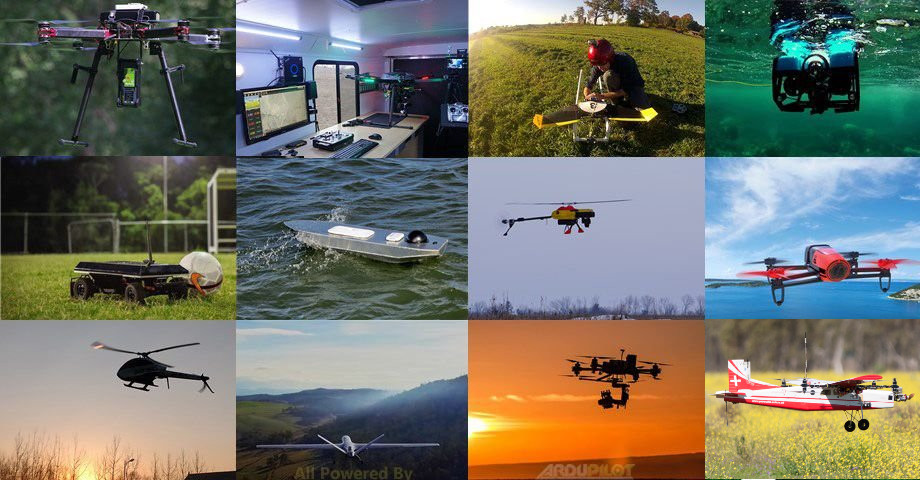
A mature open autopilot stack spanning copters, planes, rovers, boats, and submarines, starting in simulation and a small rover.
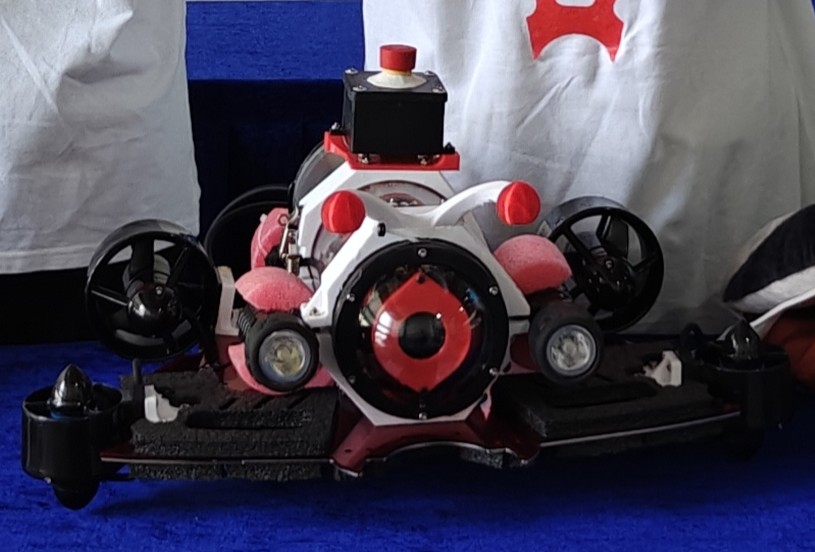
A competition-tested five-thruster AUV combining ROS 2 mission control, monocular YOLO perception, and bearing-only EKF SLAM for supervised pool autonomy.
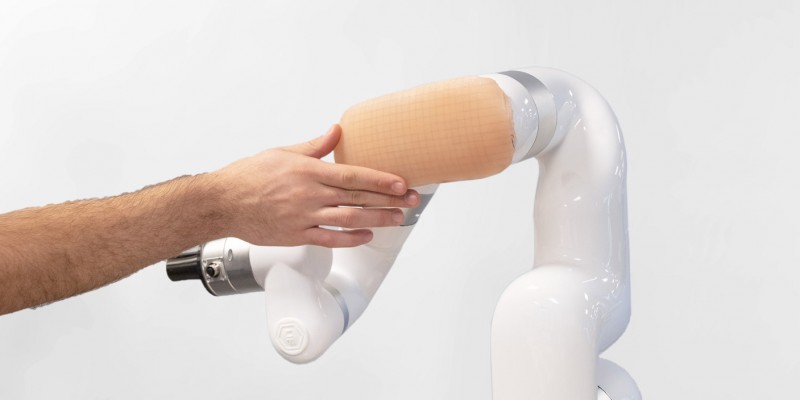
A compliant mutual-capacitance skin sensor that embeds an electrode matrix in layered silicone for precise, deformable, and replicable physical human-robot interaction research.
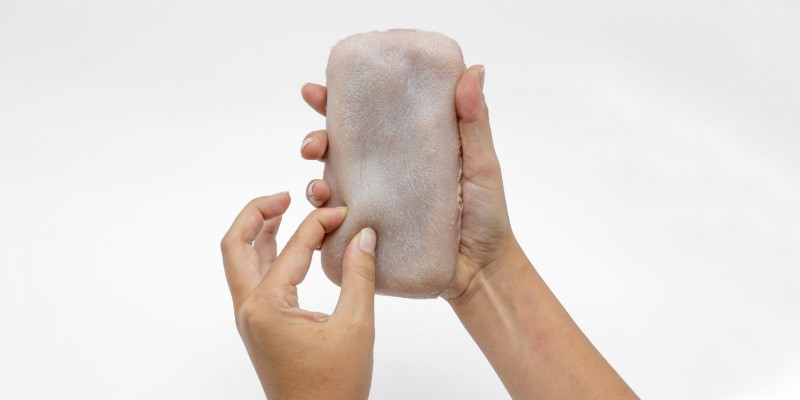
A bio-driven artificial-skin interface combining textured silicone, a conductive electrode grid, and multitouch sensing for pressure, stretch, pinch, and touch gestures.
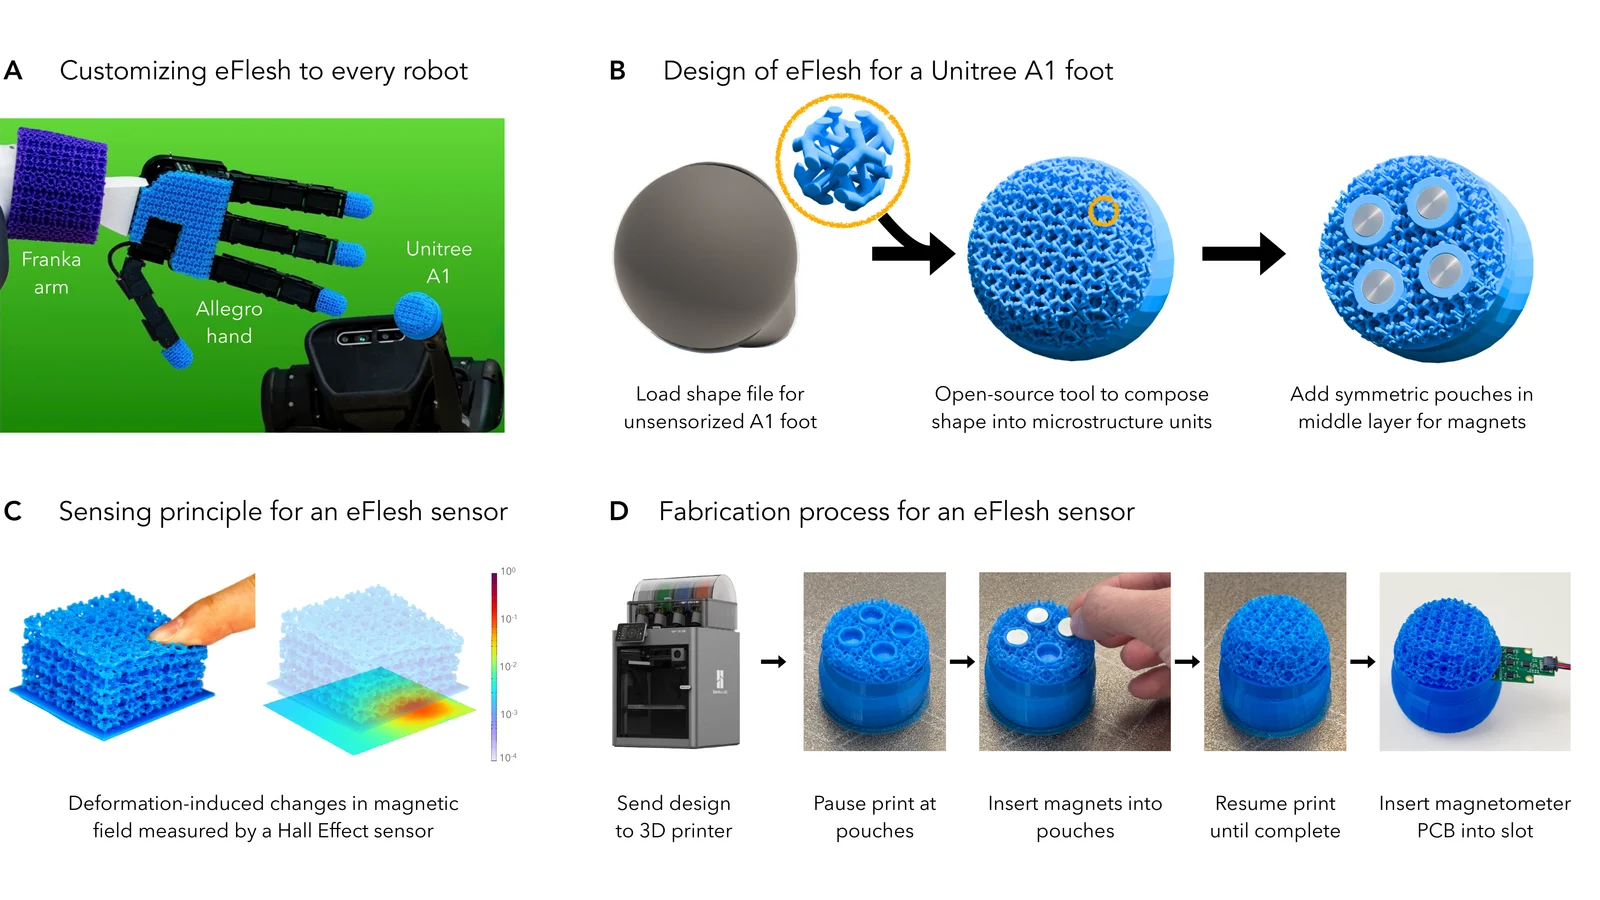
NYU's open-source touch sensor combines 3D-printed TPU microstructures, embedded magnets and a magnetometer board. A convex OBJ/STL design tool adapts it to fingertips, grippers and robot feet. Researchers report 95% slip-detection accuracy on unseen objects and 91% average success across four precise manipulation tasks; these are research results, not lab-validated guarantees.
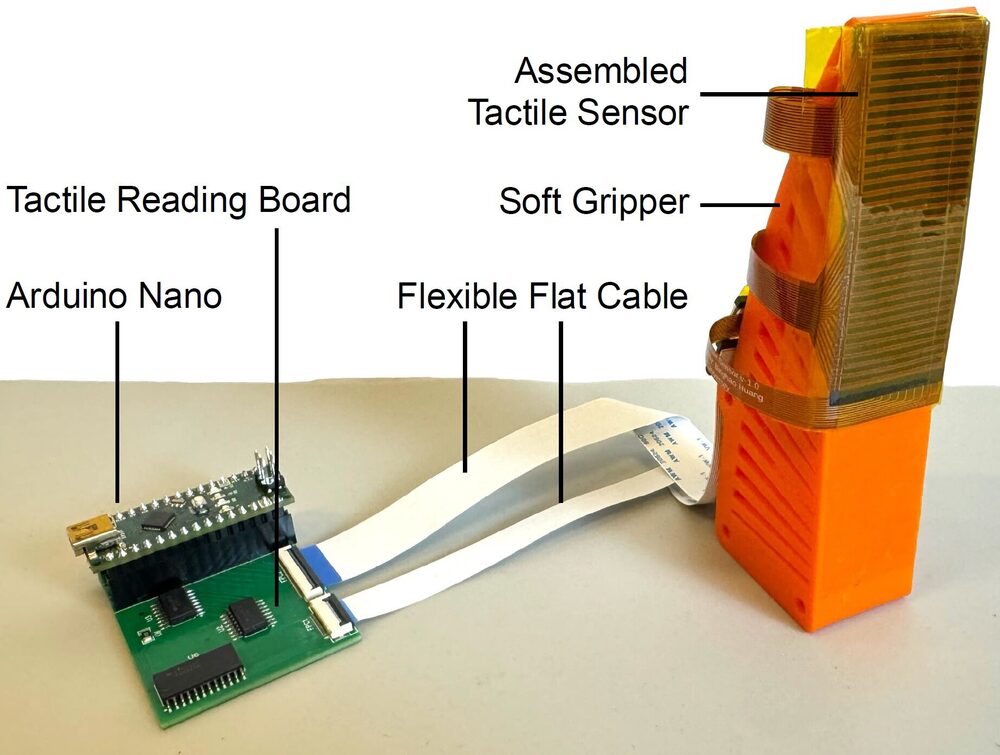
A flexible tactile sensor project for adding contact and deformation feedback to hands and grippers.
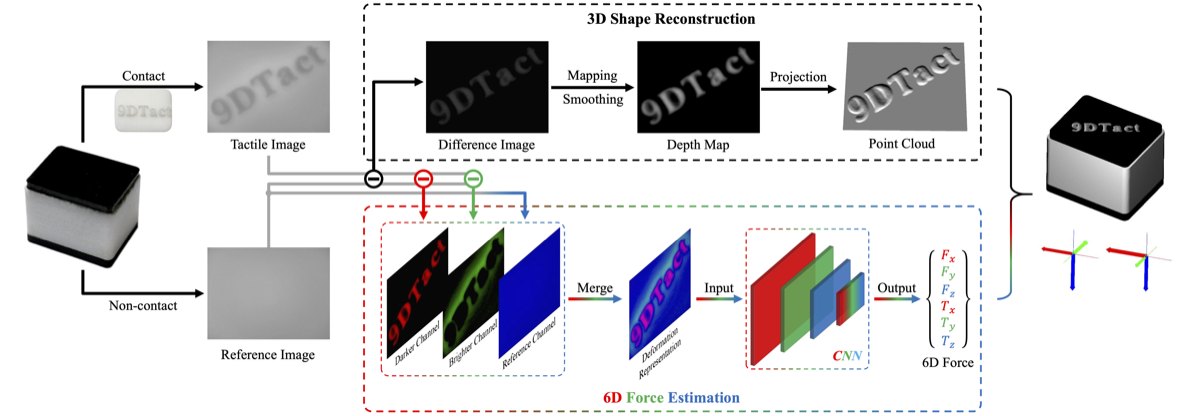
A camera-based tactile sensor that reconstructs rich contact geometry for manipulation research.
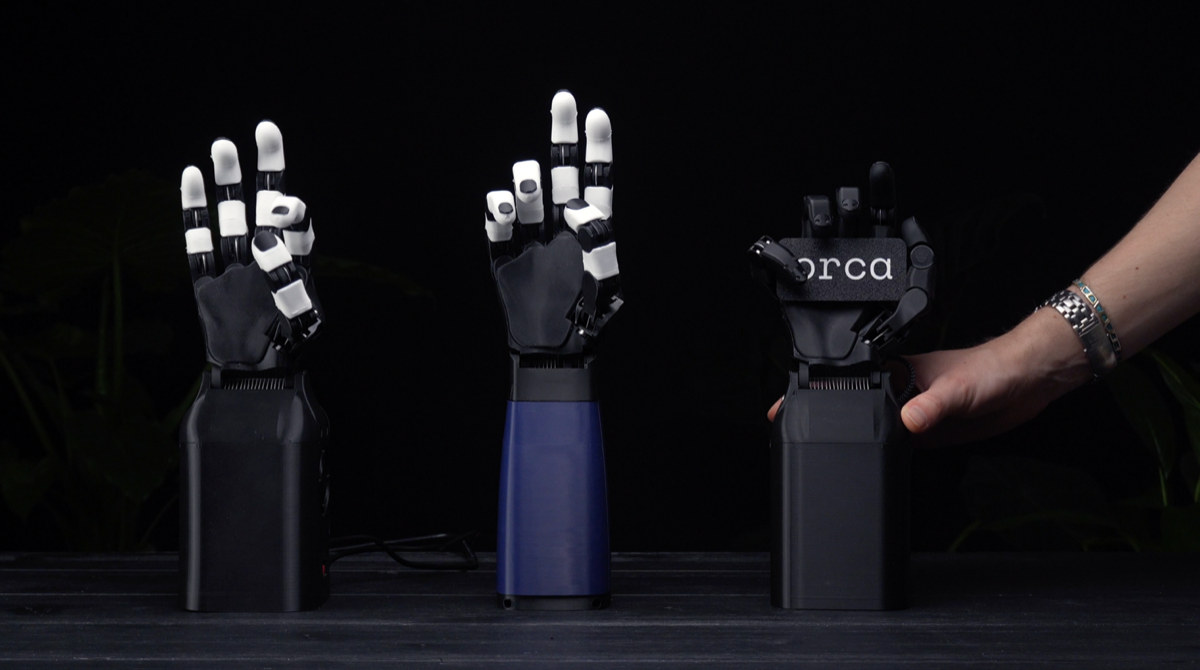
An open robotic hand focused on accessible fabrication, repairable mechanics, and dexterous control.
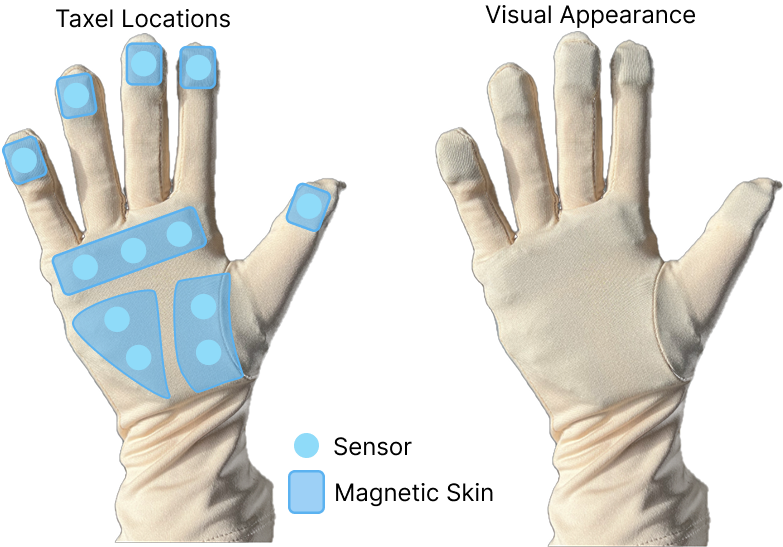
An open glove with twelve three-axis magnetic tactile sensors for human demonstrations and contact-rich robot skill transfer.
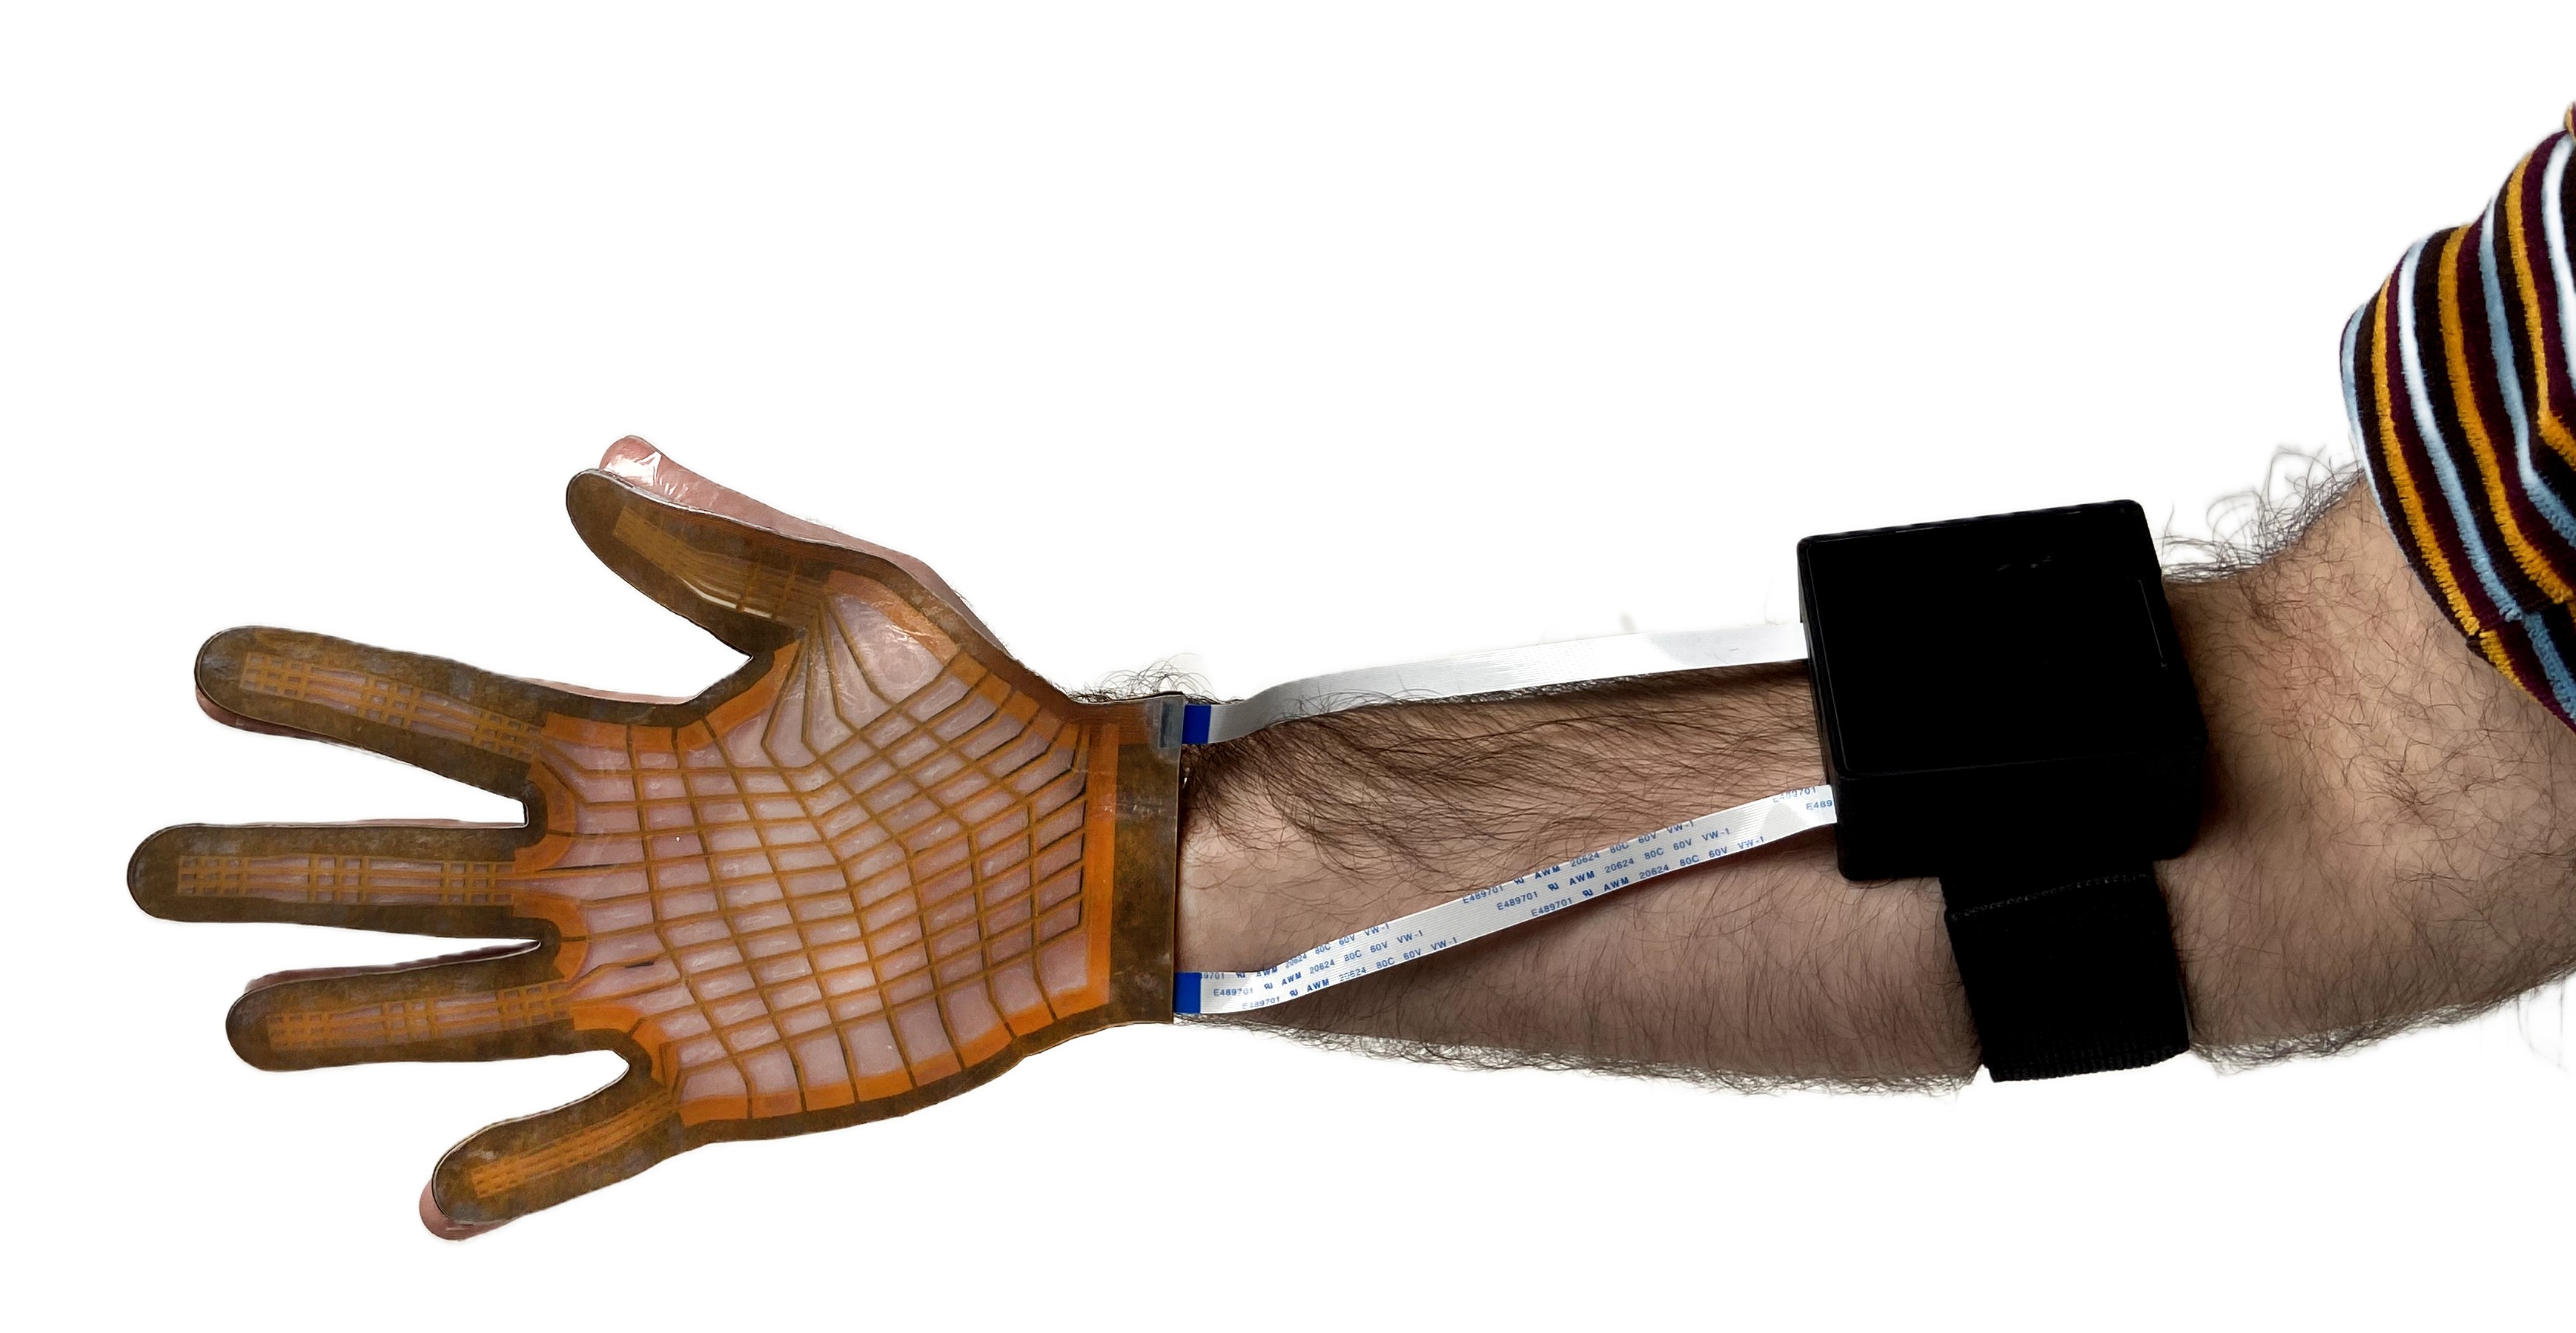
A personalized FPCB tactile glove for untethered full-hand relative-force mapping, WiReSens recording, and dexterous demonstration capture.
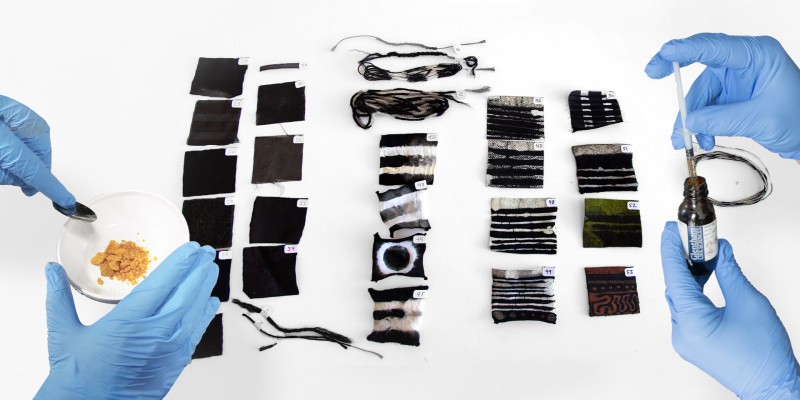
An open fabrication process that uses in-situ polymerization to turn ordinary textiles, tape, yarn, and other fibrous materials into custom conductive and piezoresistive sensors.
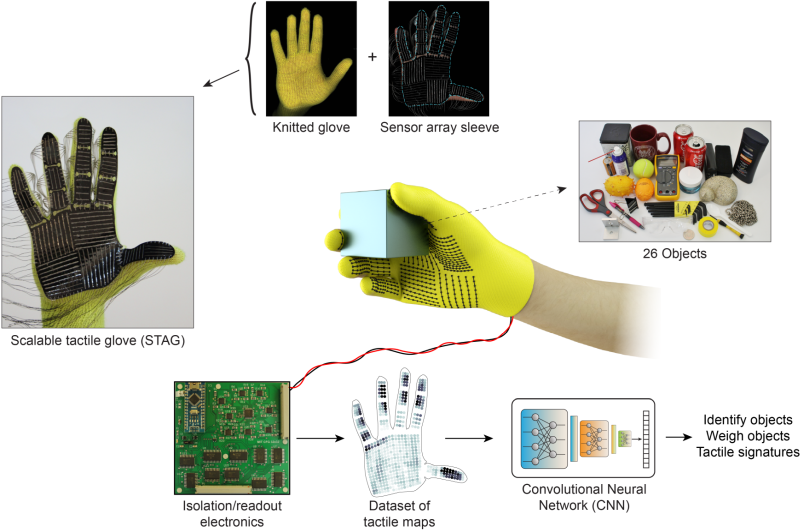
A tactile sensing research reference for learning spatial contact and grasp interactions.
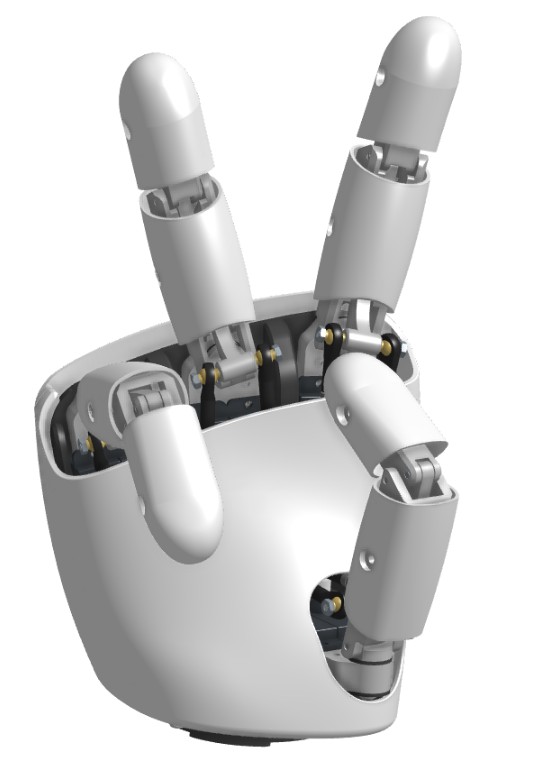
A low-cost open 3D-printable robotic hand for learning actuation, mechanics, and grasp control.
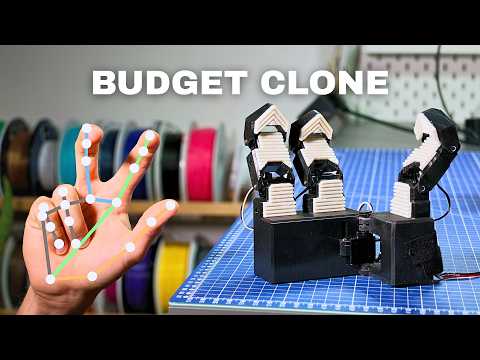
Nikodem Bartnik's independent Atlas-inspired gripper: Hackster reports seven SCS0009 servos, printed mechanics, and webcam hand tracking. A grasp-control study with no reported force or contact sensing; downloadable build files remain unverified.
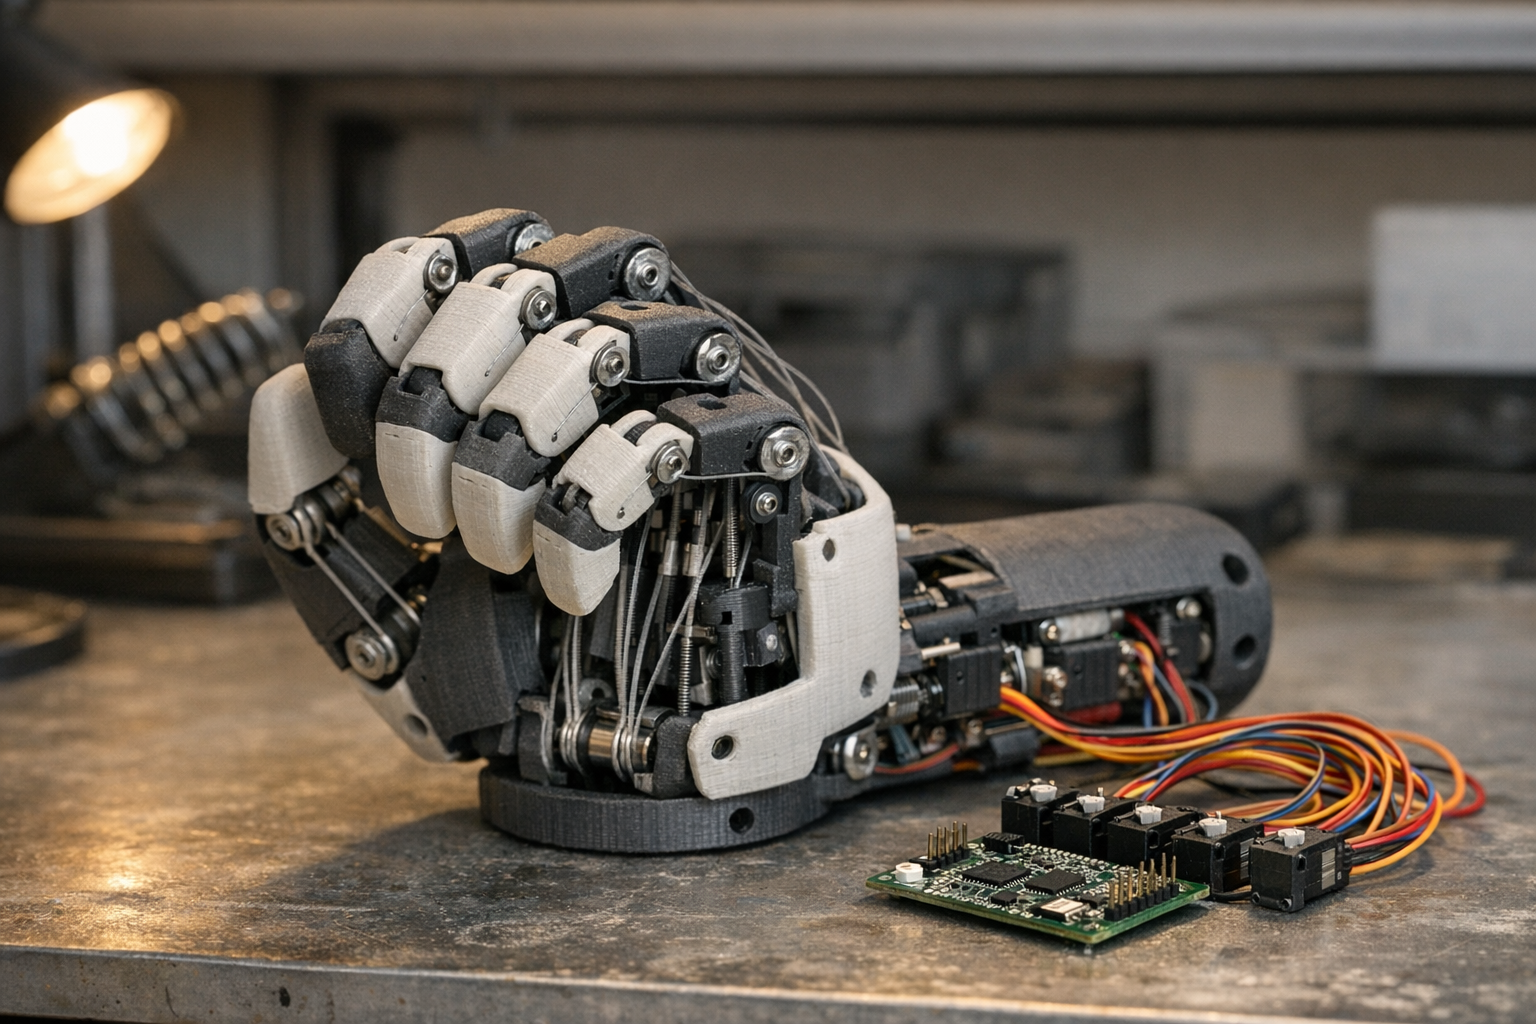
A low-cost printed humanoid hand with nineteen powered degrees of freedom for tendon routing, grasping, ROS 2, and teleoperation work.
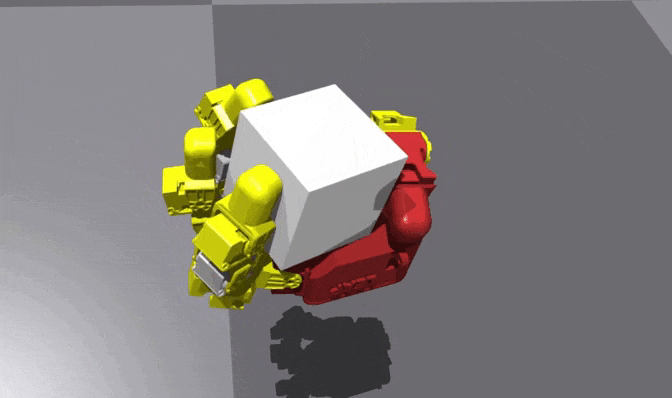
A dexterous hand platform with simulation and software APIs for learned manipulation experiments.
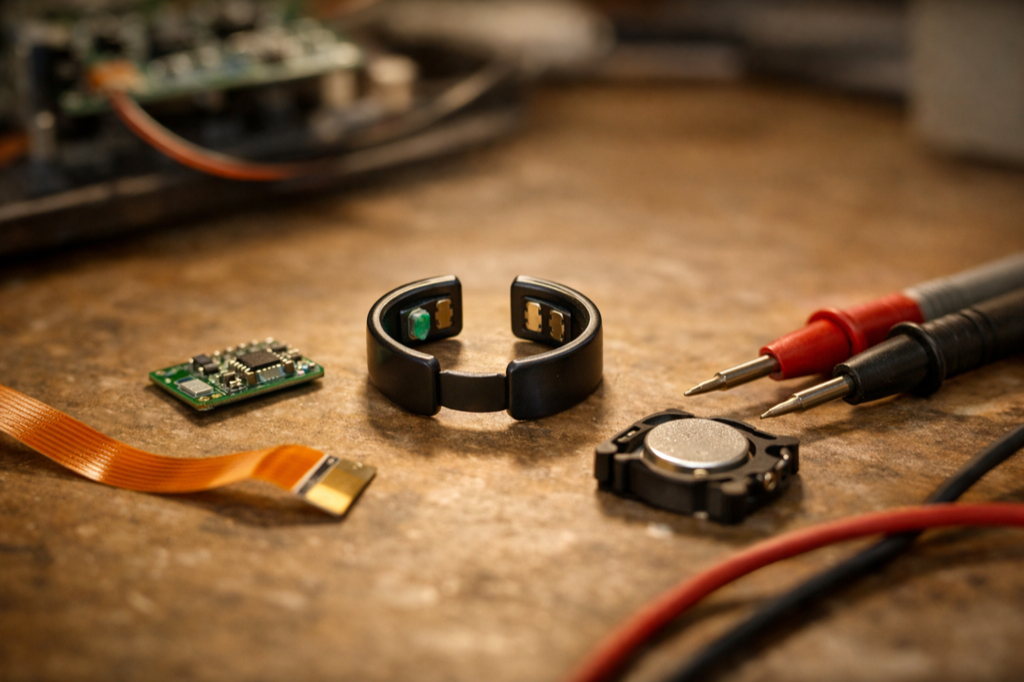
Open smart-ring data and wearable-health experiments for PPG, SpO2, heart-rate sensing, and physiological analytics.
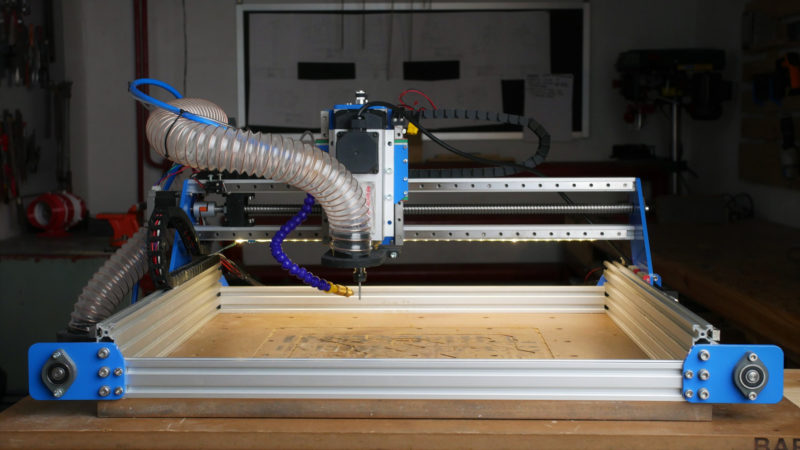
A documented metal CNC platform built from aluminum profiles, linear rails, ballscrews, laser-cut plates, and Arduino GRBL control for supervised wood, polymer, and aluminum machining.
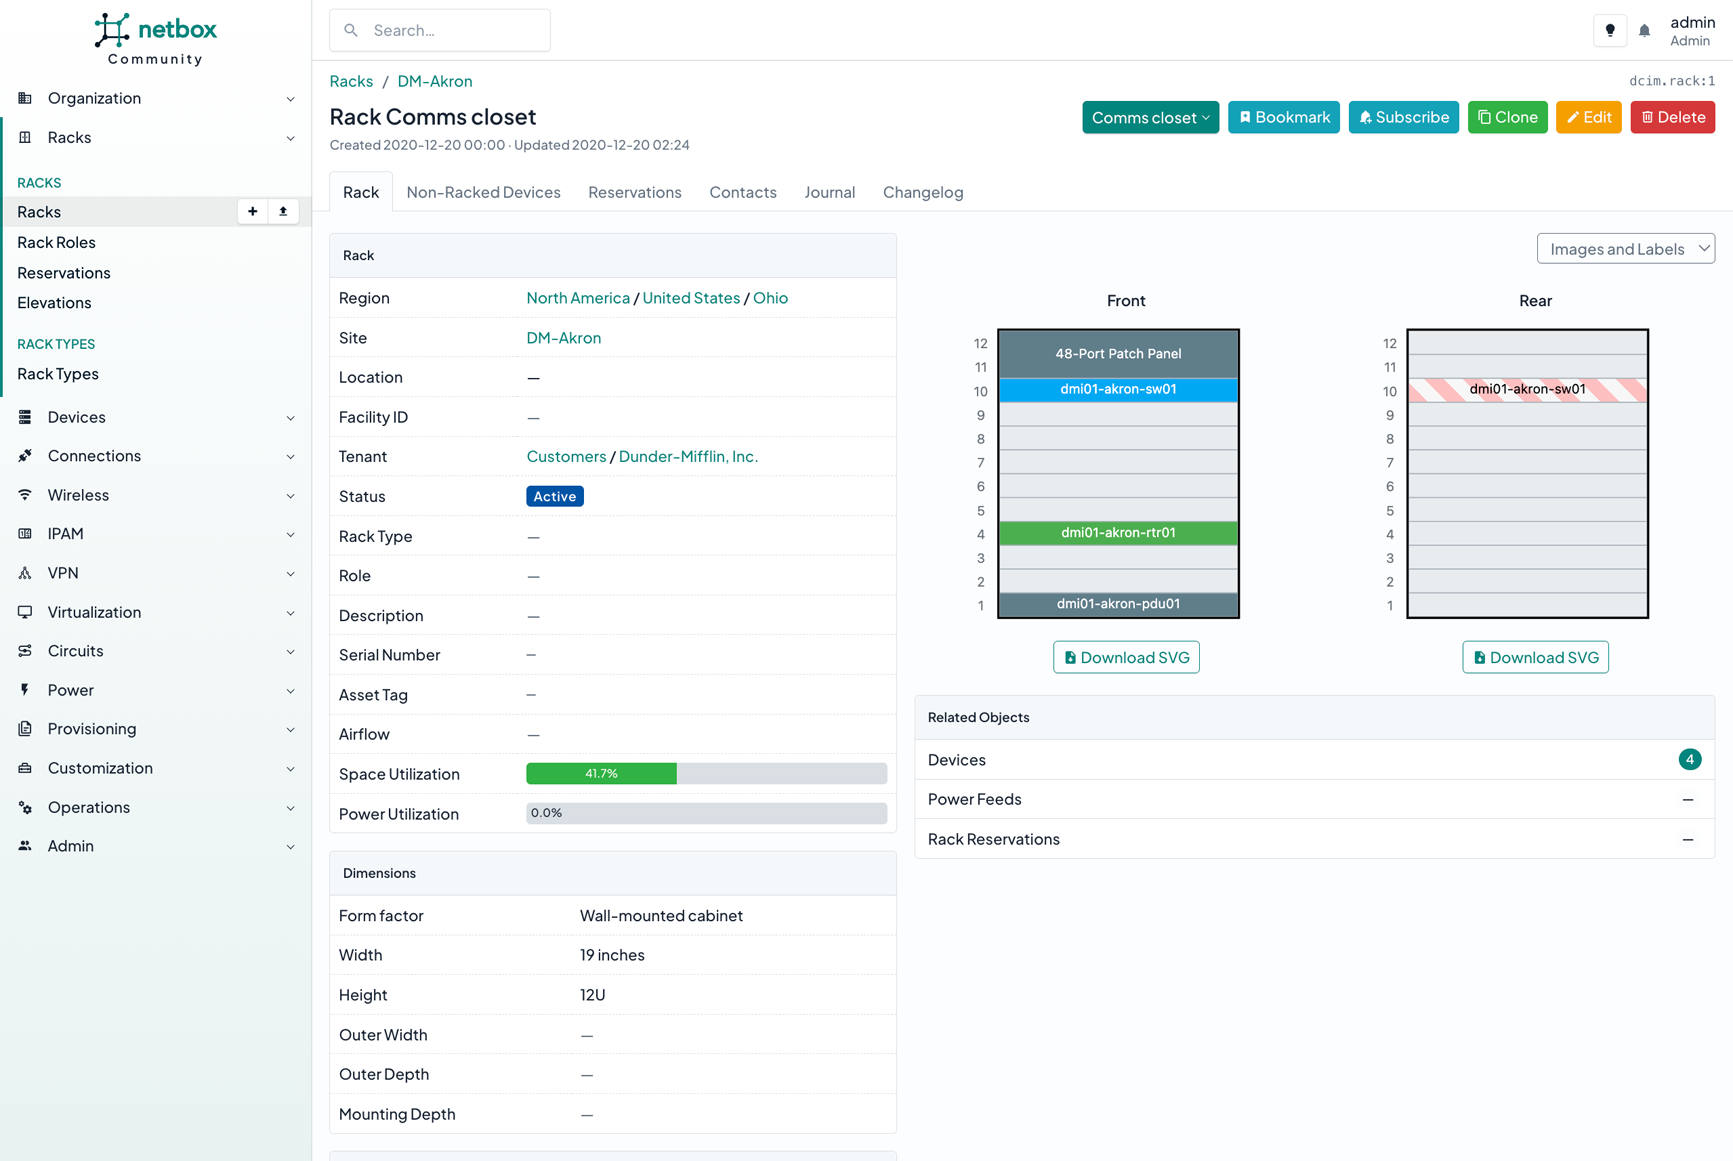
Source-of-truth inventory for lab devices, racks, networks, power, ownership, and maintenance.
Open server-management firmware for learning remote operations as the compute fleet grows.
An open network operating system track for future multi-node compute and storage infrastructure.
A local S3-compatible object layer for datasets, model artifacts, and data-lake workflows after the primary NAS is stable.
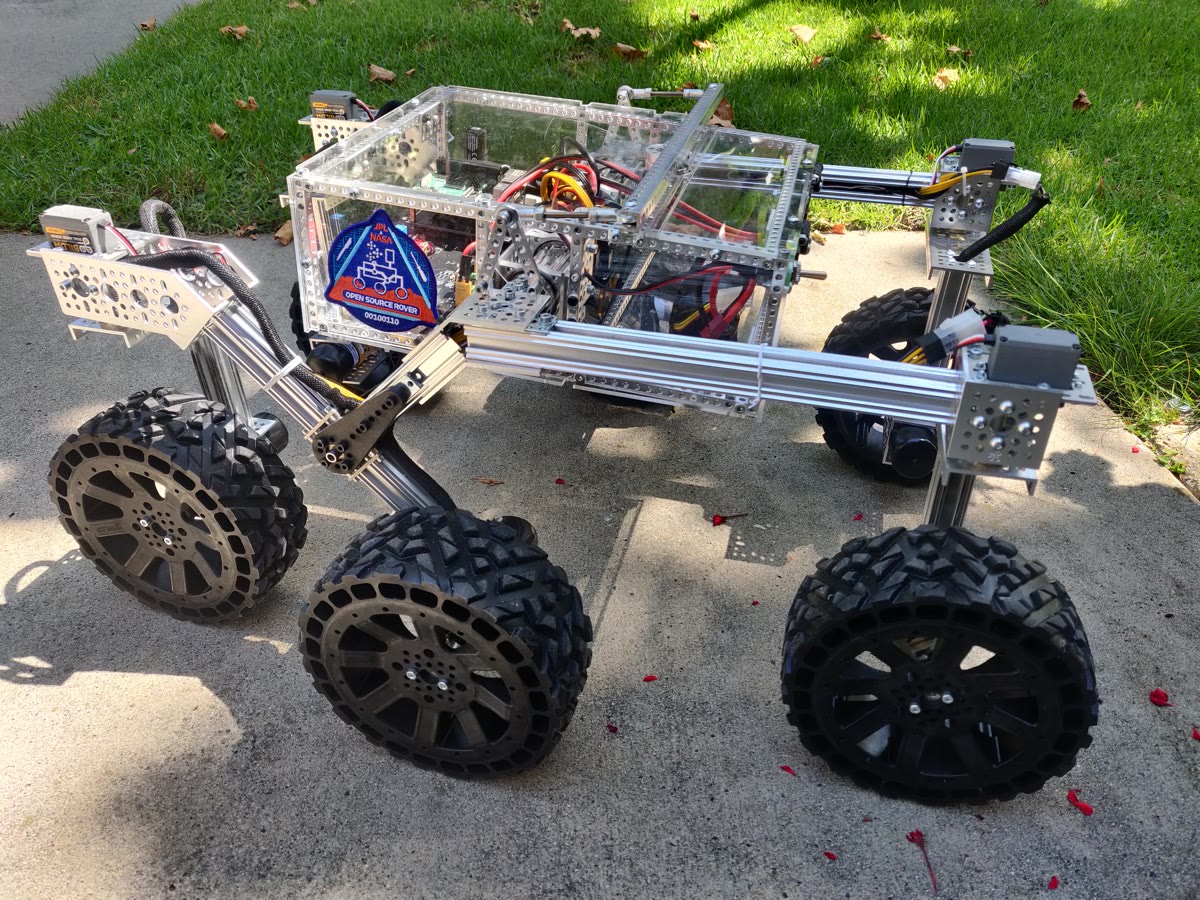
A reference rover build for mechanical assembly, locomotion, field sensing, and education.
Storage, compute, and the first embodied-AI arm loop give the lab its local backbone.
TrueNAS or OpenZFS for durable data.
A two-GPU local node before a rack.
DVC remotes for datasets and models.
S3 semantics only when projects need them.
NetBox, BMC, and networking as nodes multiply.
NAS + DVC
GPU node
Arms + robots
Local AI
Open repos
Pick a mission, bring a build log, and make the stack real. The lab is where open-source robotics leaves the README.
Build with us